SKU: DRFC-1867
📋 GST Invoice Available

Holybro Pixhawk 6X-RT Standard Set v2A

₹36,865.00 (Inclusive of all taxes)
Out of Stock

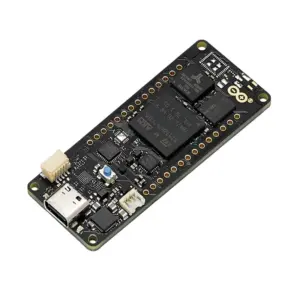
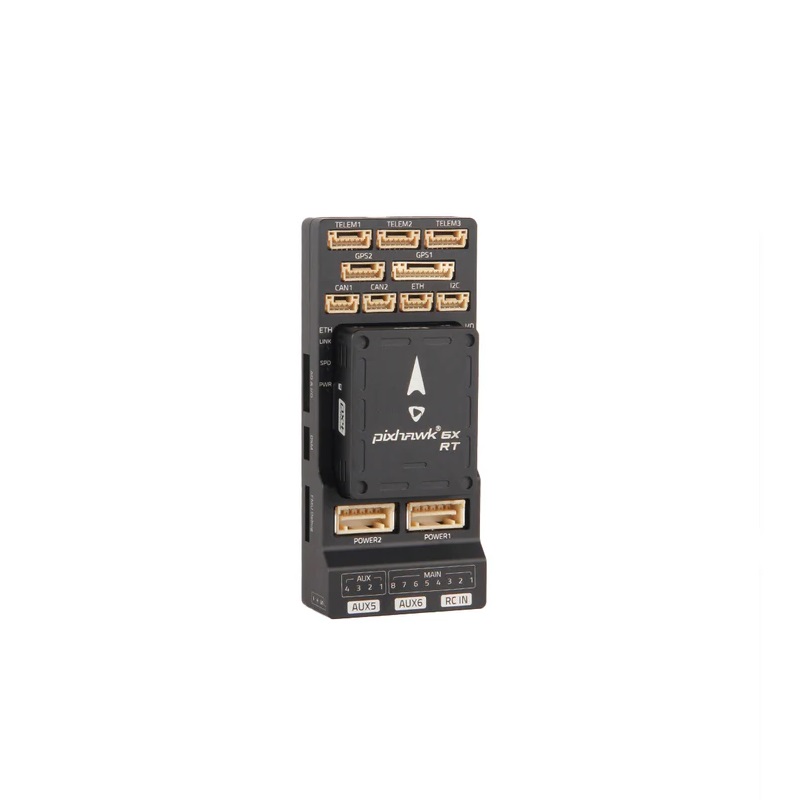
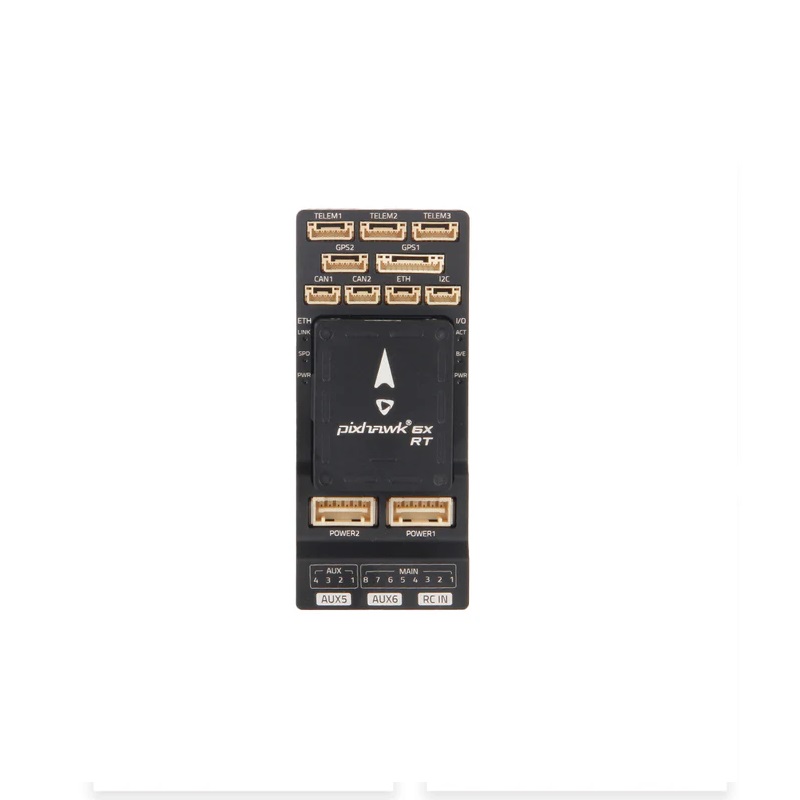
The Holybro Pixhawk 6X-RT Standard Set v2A is a high-reliability flight controller system based on the FMUv6X-RT open standard, featuring a dual-core i.MXRT1176 processor, triple-redundant IMUs, and a modular design for advanced autonomous UAV applications. It is fully compatible with PX4 Autopilot and integrates seamlessly with Pixhawk ecosystem baseboards.

Features

  • Dual-core i.MXRT1176 processor with Cortex-M7 @ 1GHz and Cortex-M4 @ 400MHz for robust flight control and real-time processing.
  • Triple-redundant sensor suite with 3x IMUs (BMI088, ICM-42670-P, ICM-42686-P) and 2x barometers (BMP388) on isolated buses for fail-safe operation.
  • Modular architecture with vibration isolation system and temperature-controlled IMUs for enhanced stability in harsh environments.
  • High-speed Ethernet interface for seamless integration with companion computers and mission systems.
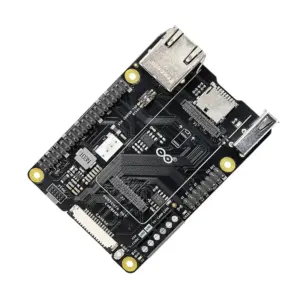
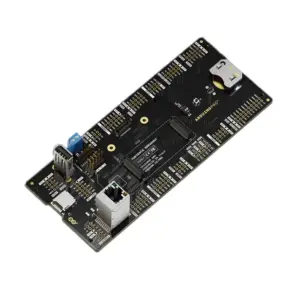
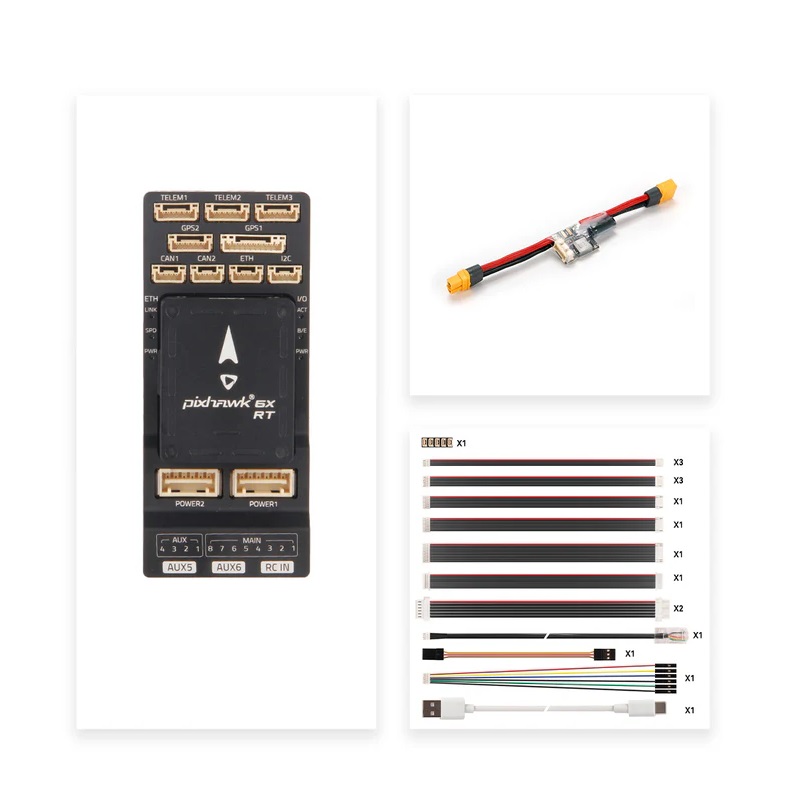
  • Includes Pixhawk 6X-RT module, Standard Baseboard v2A, PM02D HV Power Module, and cable set for a complete system solution.

Out of stock

Description

The Pixhawk 6X-RT is engineered for demanding commercial and research UAV platforms requiring maximum reliability. Its core is the NXP Semiconductors i.MXRT1176 microcontroller, providing substantial computational headroom for complex autonomy algorithms running on PX4, NuttX, or Zephyr RTOS. The system architecture employs triple redundancy domains, physically isolating sensor clusters, power rails, and communication buses to ensure continued operation even in the event of a partial hardware failure.

Advanced features like the vibration isolation mounting and onboard IMU heating resistors maintain sensor accuracy across a wide range of operational temperatures and high-vibration environments, such as those found on heavy-lift or gasoline-powered drones. The inclusion of the NXP Semiconductors EdgeLock SE051C2 secure element provides a hardware root of trust, enabling encrypted communication and protection against cyber threats for sensitive commercial applications.

Key Features

  • High-Performance Dual-Core Processor: i.MXRT1176 with 1 GHz Cortex-M7 and 400 MHz Cortex-M4 cores, 2MB SRAM, and 64MB Flash for complex flight stacks and autonomy.
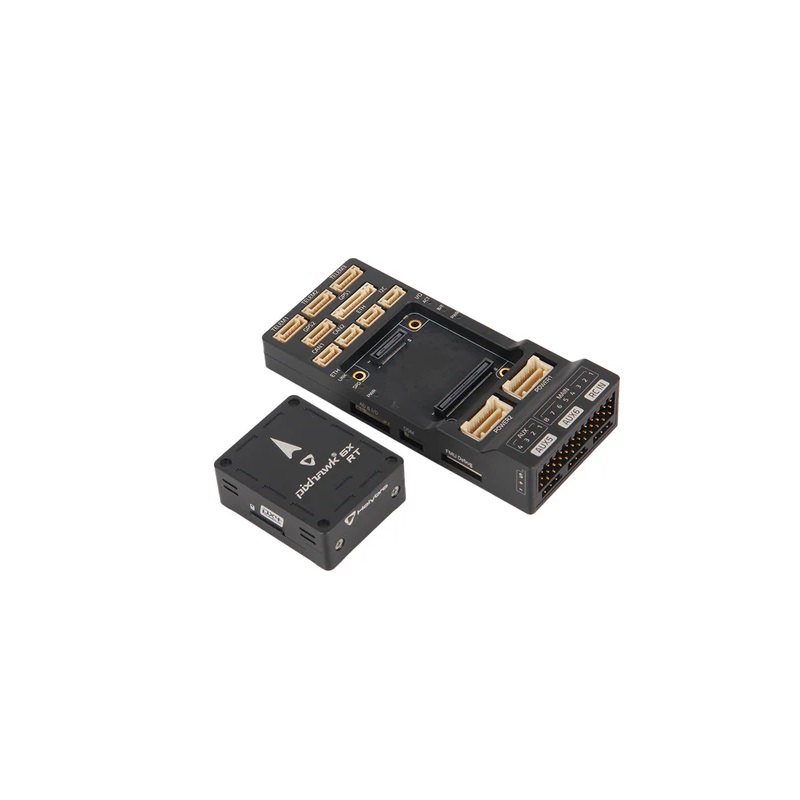
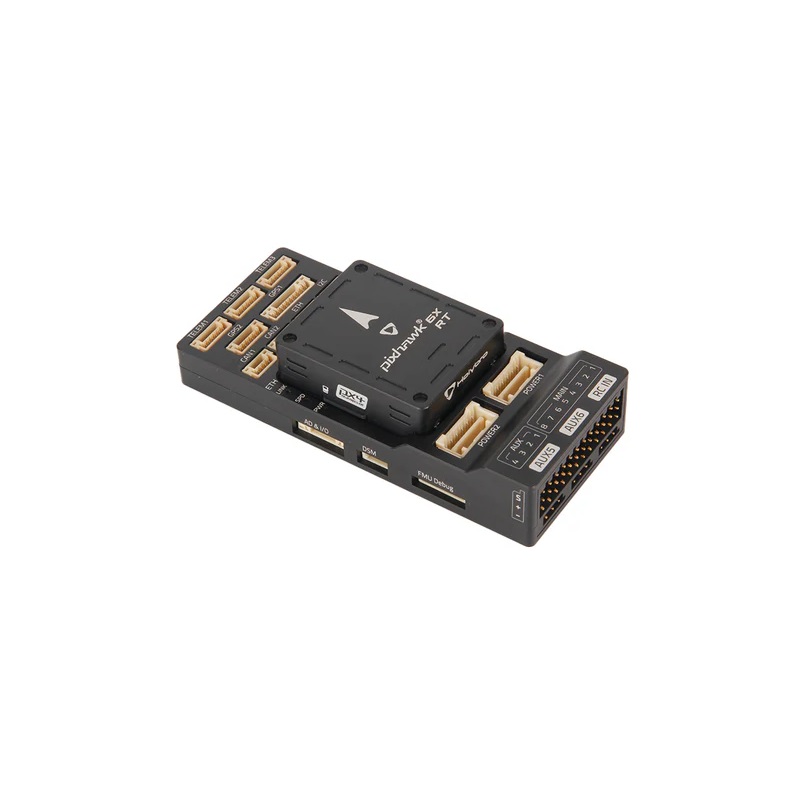
  • Modular & Redundant Design: Separated FMU, IMU, and baseboard modules with Pixhawk Autopilot Bus connectors (100-pin & 50-pin) for flexible system integration.
  • Triple-Redundant Sensor Domains: Three independent IMU sets (Bosch BMI088, InvenSense ICM-42670-P & ICM-42686-P) and two barometers (BMP388) on isolated SPI/I2C buses and power supplies.
  • Vibration & Thermal Management: Mechanical vibration isolation system and temperature-controlled IMU chambers with heating resistors ensure optimal sensor performance.
  • High-Speed Connectivity: Integrated Ethernet port enables low-latency, high-bandwidth communication with ground control stations and onboard companion computers.
  • Hardware Security Element: NXP Semiconductors EdgeLock SE051C2 secure enclave for cryptographic operations, secure boot, and key storage, certified to Common Criteria EAL6+.
  • Wide Software Support: Fully compatible with PX4 Autopilot firmware and supports NuttX and Zephyr real-time operating systems for custom development.

Applications

  • High-reliability commercial UAVs for precision agriculture, surveying, and infrastructure inspection.
  • Autonomous research platforms and development vehicles in academic and corporate R&D labs.
  • Heavy-lift cargo and delivery drones requiring robust sensor redundancy and vibration damping.
  • Industrial inspection and mapping systems integrating high-bandwidth payloads via Ethernet.
  • Secure, mission-critical UAV systems requiring hardware-based cyber-security protection.

Technical Specifications

Core ProcessorNXP Semiconductors i.MXRT1176 (Cortex-M7 @ 1 GHz, Cortex-M4 @ 400 MHz)
Memory2MB SRAM, 64MB Flash
IMU SensorsBMI088, ICM-42670-P, ICM-42686-P (Triple Redundant)
MagnetometerBMM150
Barometer2x BMP388 (Dual Redundant)
IO ProcessorSTM32F103
Secure ElementNXP Semiconductors EdgeLock SE051C2
Primary Voltage Input6V (via PM02D Power Module)
Firmware/OSPX4 Autopilot, NuttX RTOS, Zephyr RTOS
ConnectivityHigh-speed Ethernet, Pixhawk Autopilot Bus (100-pin & 50-pin)
Module DimensionsApprox. 15 x 10 x 7 cm (Shipping Box)
Module WeightApprox. 0.253 kg

Frequently Asked Questions

What is the primary processor in the Pixhawk 6X-RT and what are its capabilities?

The Pixhawk 6X-RT is built around the NXP Semiconductors i.MXRT1176 crossover processor. It features a high-performance 1 GHz Arm Cortex-M7 core for main flight control and a 400 MHz Cortex-M4 core for real-time safety tasks. This dual-core architecture, combined with 2MB of SRAM and 64MB of Flash, provides ample resources for running complex PX4 Autopilot stacks, autonomy algorithms, and high-bandwidth communication protocols simultaneously.

How does the sensor redundancy and vibration isolation work on this flight controller?

The controller implements triple redundancy by housing three separate IMU chips (BMI088, ICM-42670-P, ICM-42686-P) on independent power and data buses. The flight stack can vote on sensor data or switch to a healthy unit if a failure is detected. The vibration isolation system uses a mechanical damping mount between the main board and the IMU module to filter out high-frequency vibrations from motors and propellers, ensuring cleaner accelerometer and gyroscope readings for stable flight.

What is included in the 'Standard Set v2A' package and what additional hardware is needed?

The Standard Set includes the core Pixhawk 6X-RT flight controller module, the Pixhawk Standard Baseboard v2A which provides PWM/S.Bus/DSM inputs and actuator outputs, a PM02D HV Power Module for voltage regulation and current sensing, and a necessary cable set. To complete a system, you will need a compatible radio control receiver (e.g., PWM, SBUS, or DSMX), telemetry radios (optional), GPS/Compass module (highly recommended), and your vehicle's motors, ESCs, and propellers.

Can the Pixhawk 6X-RT be used with ArduPilot firmware, or is it limited to PX4?

While the Pixhawk 6X-RT is designed and optimized for the PX4 Autopilot ecosystem, its hardware is based on the open FMUv6X-RT standard. Porting ArduPilot is theoretically possible due to community efforts, but it is not officially supported out-of-the-box. For guaranteed full functionality, including leveraging all redundant sensors and the secure element, using the PX4 firmware is strongly recommended.

Package Includes

  • 1 x Pixhawk 6X-RT Flight Controller Module
  • 1 x Pixhawk Standard Baseboard v2A
  • 1 x PM02D HV Power Module
  • 1 x Cable Set

Additional Information

Weight 0.253 kg
Dimensions 10 × 15 × 7 cm