SKU: SENS-1032
📋 GST Invoice Available

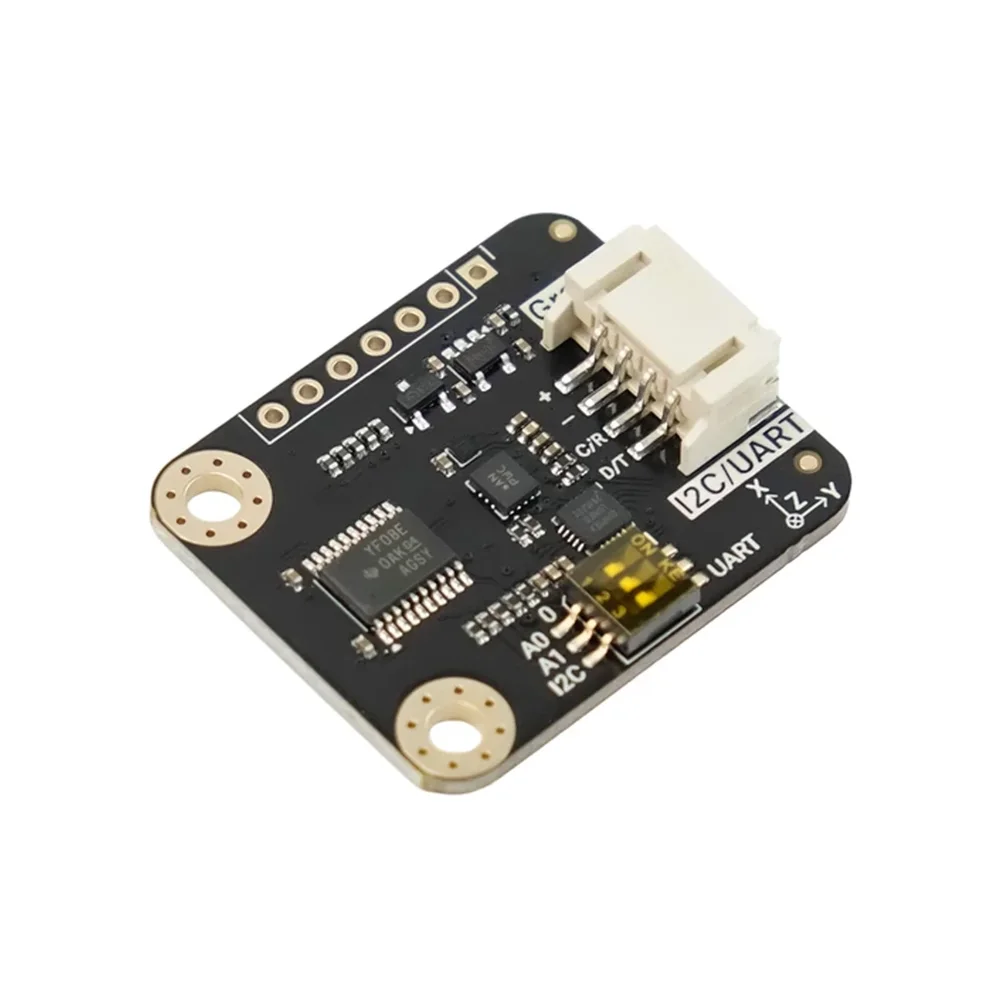
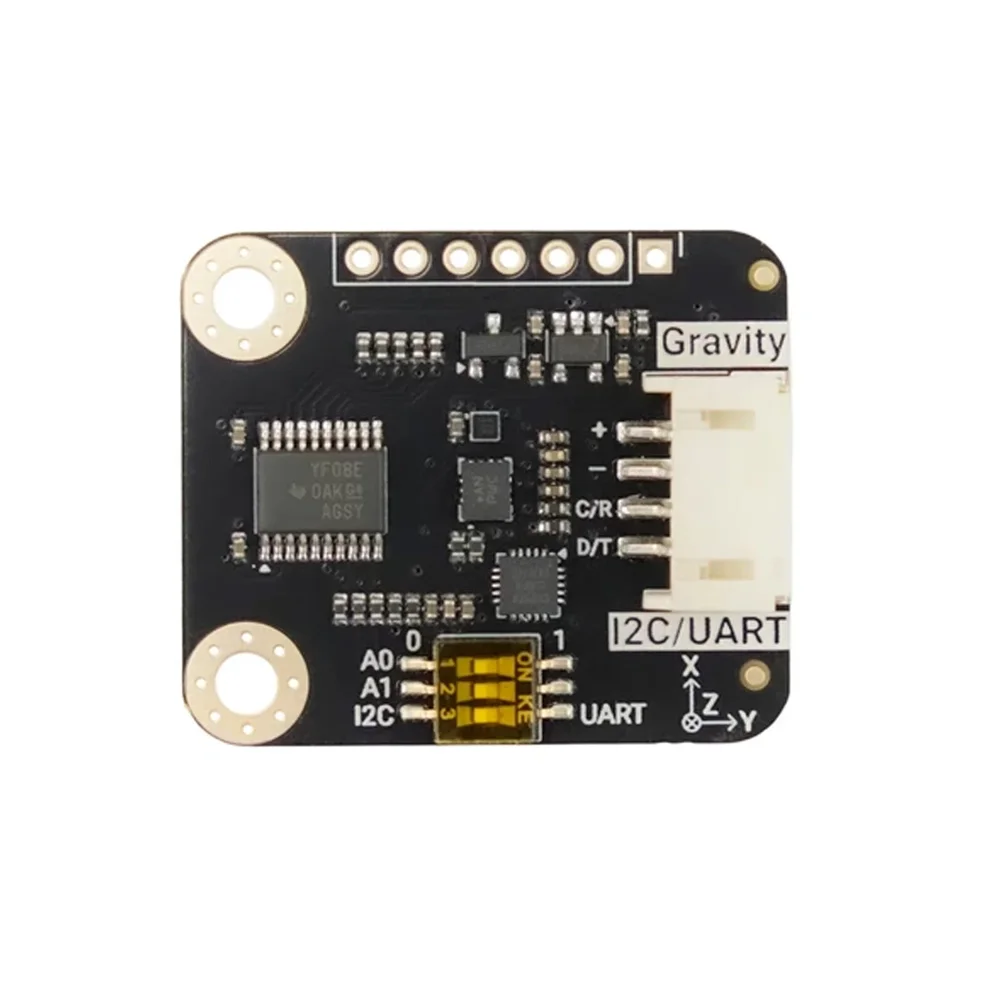
DFRobot Gravity BMI323+BMM350 9DOF IMU Sensor Module (I2C/UART, Plug & Play)

₹2,309.00 (Inclusive of all taxes)
Out of Stock

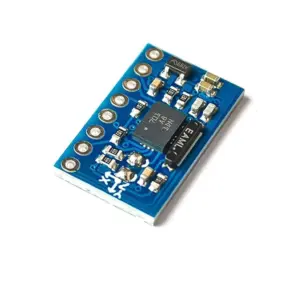
The DFRobot Gravity BMI323+BMM350 is a 9DOF IMU sensor module integrating Bosch accelerometer, gyroscope, and magnetometer ICs for precise motion and orientation tracking. It operates from 3.3V to 5V DC and communicates via I2C or UART, offering plug-and-play compatibility with Arduino, Raspberry Pi, ESP32, and other embedded platforms.

Features

  • Bosch BMI323 (6-Axis) + BMM350 (3-Axis Magnetometer) sensor fusion for 9DOF motion sensing.
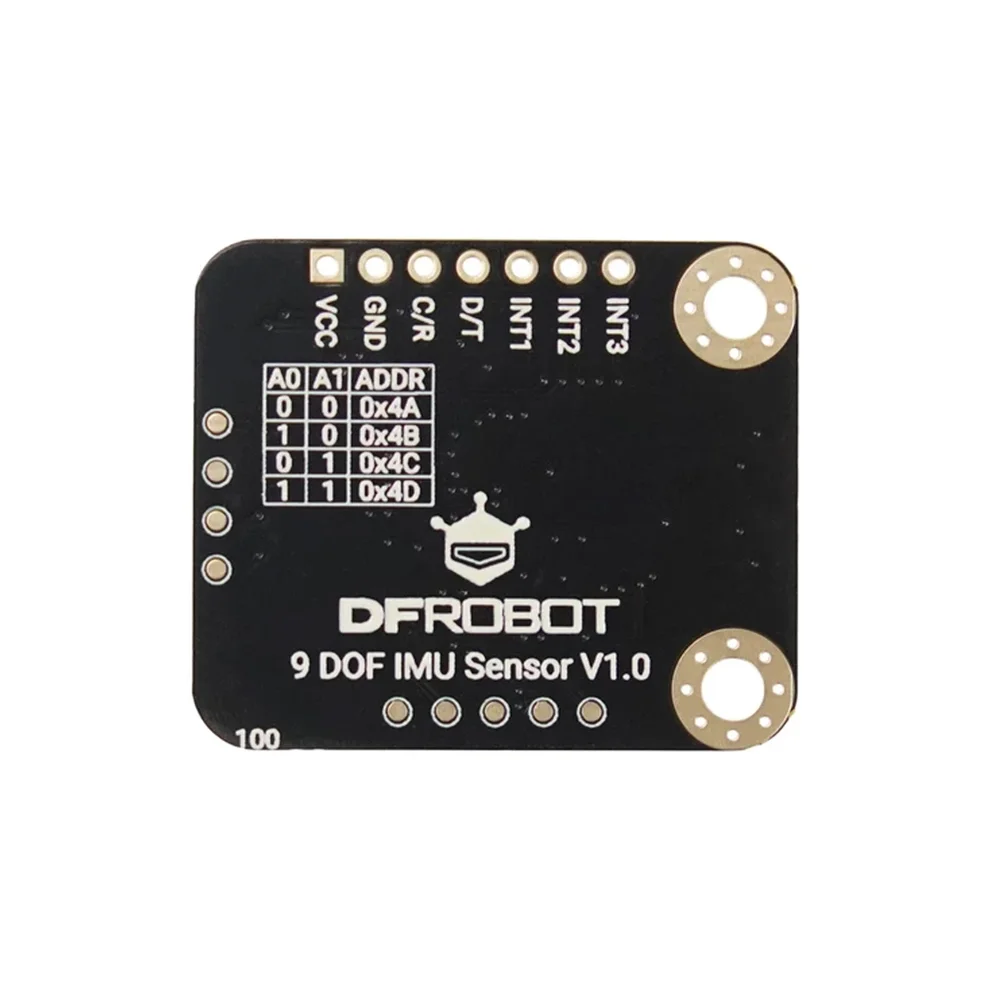
  • Dual I2C and UART communication interfaces with four selectable I2C addresses (0x4A-0x4D).
  • Wide configurable ranges: Accelerometer (±2g to ±16g), Gyroscope (±125 to ±2000°/s), Magnetometer (±2000µT).
  • Three programmable interrupt pins and built-in motion event detection for efficient system integration.
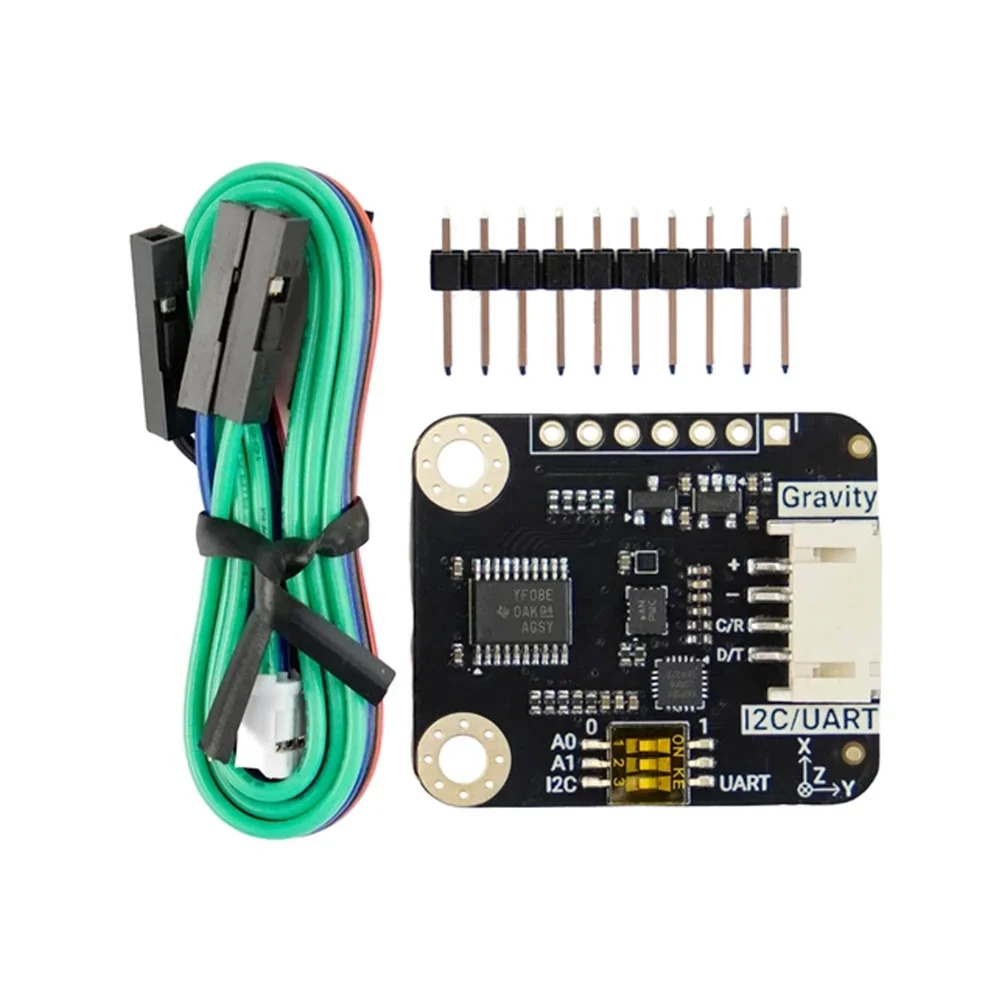
  • Gravity PH2.0-4P connector and pin header for rapid prototyping and plug-and-play wiring.

Out of stock

Description

This IMU module combines the Bosch BMI323 6-axis inertial measurement unit (3-axis accelerometer + 3-axis gyroscope) with the Bosch BMM350 3-axis magnetometer to deliver a complete 9-degree-of-freedom motion sensing solution. The integrated sensor fusion provides accurate acceleration, angular rate, and magnetic field data, enabling robust orientation tracking and heading-aware applications such as electronic compasses.

The module supports both I2C and UART serial communication protocols, allowing flexible integration into various microcontroller ecosystems. Its wide operating voltage range (3.3V to 5V DC) ensures compatibility with 3.3V logic systems like Raspberry Pi and ESP32, as well as 5V Arduino boards. The inclusion of four software-selectable I2C addresses facilitates the use of multiple sensors on a single bus without address conflicts.

Key Features

  • High-precision 9DOF sensing using Bosch's proven BMI323 and BMM350 MEMS sensors.
  • Dual I2C/UART interface with configurable data output rates (ODR) up to 6400 Hz for accelerometer/gyroscope.
  • Four configurable I2C addresses (0x4A, 0x4B, 0x4C, 0x4D) for multi-sensor system design.
  • Three dedicated programmable interrupt pins supporting motion detection events (e.g., any-motion, no-motion).
  • 16-bit digital resolution for accelerometer and gyroscope outputs, ensuring fine measurement granularity.
  • Compact PCB design (32 x 27 mm) with 3mm mounting holes for secure mechanical integration.
  • Gravity plug-and-play ecosystem connector (PH2.0-4P) simplifies wiring and reduces prototyping time.
  • Low operating current of 3.42 mA, optimized for battery-powered wearable and portable devices.

Applications

  • Robotics navigation and orientation feedback for autonomous platforms.
  • Wearable device motion tracking and gesture recognition.
  • Electronic compass and heading reference systems for drones and UAVs.
  • Stabilization and tilt sensing in handheld controllers and VR/AR equipment.
  • Embedded system motion event detection for IoT and industrial monitoring.

Technical Specifications

Sensor CombinationBosch BMI323 + Bosch BMM350
Sensor Type9DOF IMU (Accelerometer, Gyroscope, Magnetometer)
Operating VoltageDC 3.3V – 5V
Operating Current3.42 mA (typical)
Communication InterfaceI²C / UART
Default I²C Address0x4A (Configurable: 0x4B, 0x4C, 0x4D)
Programmable Interrupt Pins3
Accelerometer Range±2g, ±4g, ±8g, ±16g (selectable)
Accelerometer Resolution16-bit
Accelerometer ODR0.78125 Hz – 6400 Hz
Gyroscope Range±125, ±250, ±500, ±1000, ±2000°/s (selectable)
Gyroscope Resolution16-bit
Gyroscope ODR0.78125 Hz – 6400 Hz
Magnetometer Range±2000 µT
Magnetometer ResolutionApprox. 0.1 µT
Magnetometer Max Trigger Frequency200 Hz
Connector TypePH2.0-4P (Gravity) / 2.54mm Pin Header
PCB Dimensions32 x 27 mm
Mounting Hole Spacing20 mm
Mounting Hole Diameter3 mm
Weight4 g

Frequently Asked Questions

What is the difference between this 9DOF IMU and a standard 6DOF IMU?

This module adds a 3-axis magnetometer (BMM350) to the standard 6-axis accelerometer and gyroscope (BMI323), providing a full 9 degrees of freedom. The magnetometer enables absolute heading (North) reference, making it suitable for electronic compass applications and orientation tracking where Earth's magnetic field sensing is required, unlike 6DOF IMUs which only measure relative motion.

How do I select between I2C and UART communication?

The interface is selected via hardware configuration. The module uses the same set of pins for both protocols. You must configure your microcontroller's serial peripheral to match the chosen protocol and ensure the correct library (I2C or UART) is used in your code. The default communication upon power-up is I2C.

Can I use multiple sensors on the same I2C bus?

Yes. The module supports four software-selectable I2C addresses (0x4A, 0x4B, 0x4C, 0x4D). You can change the address via a configuration command before connecting multiple units, allowing you to operate several IMUs on a single I2C bus without address conflicts.

What is the purpose of the three interrupt pins?

The three programmable interrupt pins (INT1, INT2, INT3) can be configured to trigger on specific sensor events, such as motion detection, data ready, or FIFO watermark. This allows the host microcontroller to operate in a low-power sleep mode and wake only when new motion data is available or a predefined event occurs, improving system efficiency.

Is this sensor compatible with 5V Arduino boards?

Yes. The module operates from 3.3V to 5V DC, making it fully compatible with 5V Arduino boards like the Uno. The I2C and UART logic levels are also tolerant of 5V signals. For 3.3V boards like ESP32 or Raspberry Pi, no level shifting is required.

Package Includes

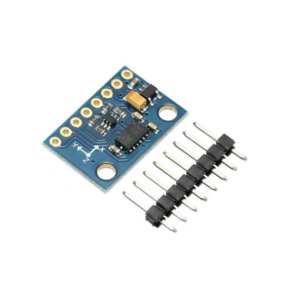
  • 1 x Gravity: High Precision 9 DOF IMU Sensor Module
  • 1 x Gravity 4-Pin Sensor Cable (PH2.0-4P)
  • 1 x 2.54mm 10-Pin Single Row Pin Header

Additional Information

Weight 0.004 kg
Dimensions 2.7 × 3.2 cm