SKU: DRFC-1866
📋 GST Invoice Available

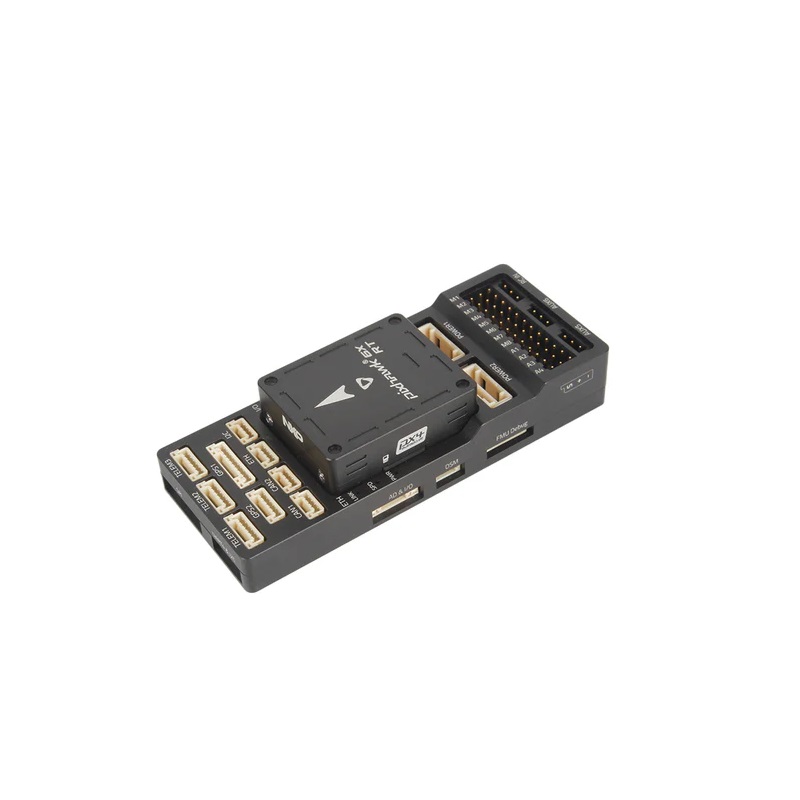
Holybro Pixhawk 6X-RT Standard Set v2B

₹42,979.00 (Inclusive of all taxes)
Out of Stock

The Holybro Pixhawk 6X-RT Standard Set v2B is a high-reliability flight controller module based on the FMUv6X-RT open standard, featuring a dual-core NXP Semiconductors i.MXRT1176 processor, triple-redundant IMUs, and dual barometers for robust autonomous drone and robotic applications compatible with ArduPilot and PX4.

Features

  • Dual-Core NXP Semiconductors i.MXRT1176 MCU with 1GHz Cortex-M7 and 400MHz Cortex-M4 cores.
  • Triple-redundant IMU sensors (BMI088, ICM-42670-P, ICM-42686-P) and dual-redundant BMP388 barometers.
  • Integrated vibration isolation system and temperature-controlled IMU heating for stable sensor readings.
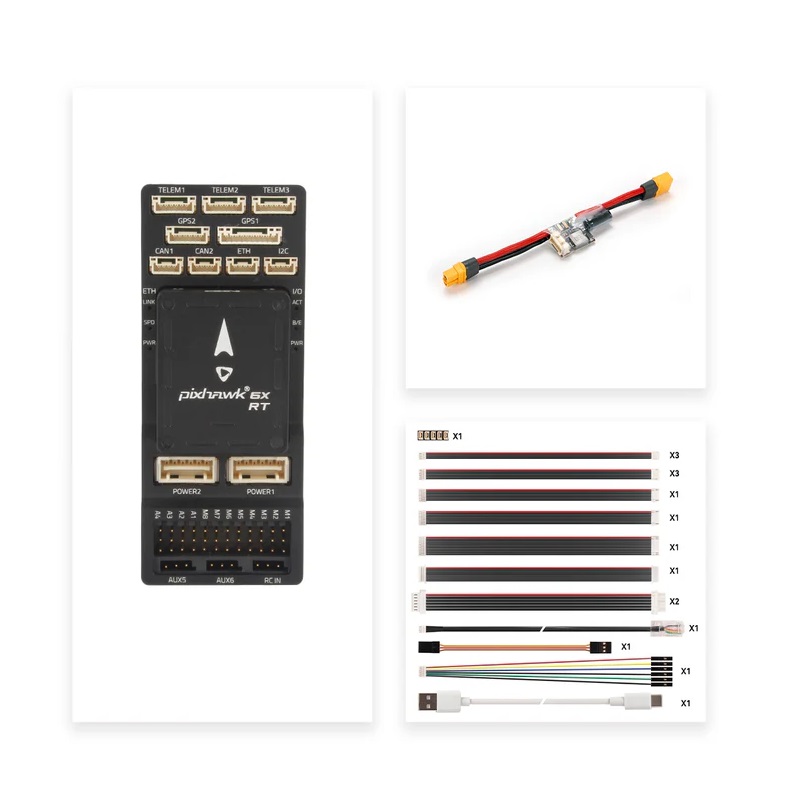
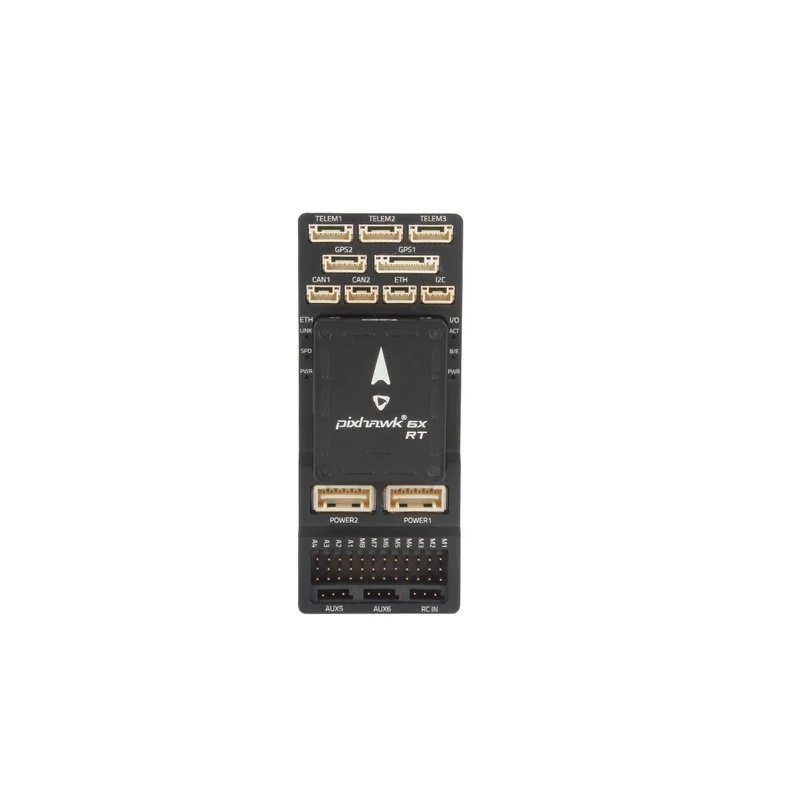
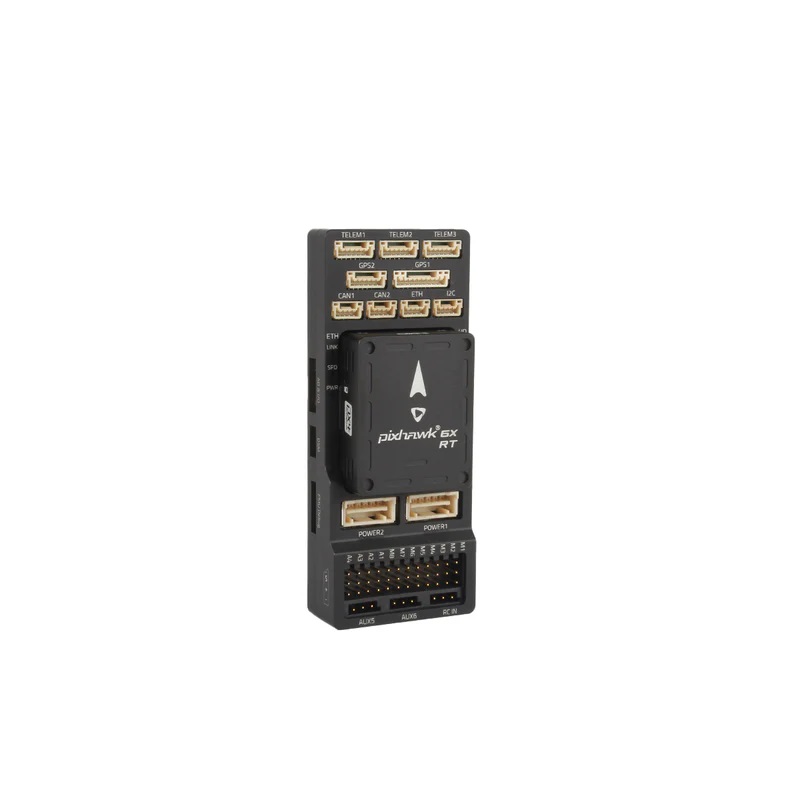
  • Includes Pixhawk 6X-RT module, Standard Baseboard v2B, PM02D HV Power Module, and cable set.
  • Features NXP Semiconductors EdgeLock SE051 secure element (CC EAL 6+) for secure field updates and high-speed Ethernet interface.

Out of stock

Description

The Pixhawk 6X-RT flight controller is engineered for mission-critical autonomous systems, leveraging a modular architecture that separates the Flight Management Unit (FMU), Inertial Measurement Units (IMUs), and baseboard via the Pixhawk Autopilot Bus. This design, combined with isolated power domains and independent sensor buses, provides exceptional fault tolerance and operational stability in demanding environments.

Its high-performance dual-core processor enables complex navigation algorithm execution, while the integrated hardware security module ensures protected firmware updates and system integrity. The inclusion of a dedicated Ethernet port facilitates seamless, high-bandwidth communication with companion computers for advanced payload integration and real-time data processing.

Key Features

  • High-Performance Dual-Core Processor: NXP Semiconductors i.MXRT1176 with Cortex-M7 @ 1GHz and Cortex-M4 @ 400MHz, supported by 2MB SRAM and 64MB Octal SPI Flash.
  • Advanced Sensor Redundancy: Three independent IMU sensors (BMI088, ICM-42670-P, ICM-42686-P) and two BMP388 barometers on separate SPI buses with isolated power control.
  • Vibration & Thermal Management: Mechanical vibration isolation and onboard heating resistors maintain optimal IMU operating temperatures for precise readings.
  • Secure Hardware Architecture: Integrated NXP Semiconductors EdgeLock SE051 secure element provides CC EAL 6+ certified security for firmware updates and system protection.
  • High-Speed Connectivity: Integrated Ethernet interface for low-latency communication with mission computers and peripherals.
  • Modular Design: FMU, IMU, and baseboard are separate modules connected via 100-pin and 50-pin Pixhawk Autopilot Bus connectors for flexibility.
  • Wide Power Input: Compatible with the included PM02D HV Power Module for robust power supply management.

Applications

  • High-reliability autonomous drones for commercial surveying, mapping, and agricultural monitoring.
  • Research and development platforms for advanced robotics and UAV algorithm testing.
  • Industrial automation systems, including warehouse logistics robots and inspection drones.
  • Heavy-lift and long-endurance UAVs requiring robust sensor redundancy and secure operation.
  • Geospatial data collection and remote sensing platforms demanding precise navigation.

Technical Specifications

Item TypeFlight Controller
Main MCUNXP Semiconductors i.MXRT1176 Dual-Core (Cortex-M7 @ 1GHz, Cortex-M4 @ 400MHz)
IO ProcessorSTM32F103
IMU SensorsBMI088, ICM-42670-P, ICM-42686-P (Triple Redundant)
MagnetometerBMM150
Barometers2x BMP388 (Dual Redundant)
Security ModuleNXP Semiconductors EdgeLock SE051 Secure Element (CC EAL 6+)
Memory2MB SRAM, 64MB Octal SPI Flash
ConnectivityEthernet, Pixhawk Autopilot Bus (100-pin & 50-pin)
Shipping Weight0.254 kg
Shipping Dimensions14 x 10 x 8 cm

Frequently Asked Questions

What firmware is compatible with the Pixhawk 6X-RT?

The Pixhawk 6X-RT is fully compatible with the latest versions of ArduPilot and PX4 open-source autopilot firmware. Its FMUv6X-RT standard design ensures direct support for advanced features like EKF3, mission planning, and secure firmware updates via the integrated EdgeLock secure element.

What is the purpose of the triple-redundant IMUs?

The triple-redundant IMUs (BMI088, ICM-42670-P, and ICM-42686-P) provide fault tolerance for critical attitude and heading reference data. Each sensor operates on an independent power domain and SPI bus, allowing the flight controller to compare readings and automatically switch to a healthy sensor if one fails, ensuring continuous stable flight in autonomous operations.

What power input does the included PM02D HV Power Module support?

The included PM02D HV Power Module supports a wide input voltage range, typically from 2S to 12S LiPo batteries (approximately 6V to 60V). It provides regulated 5V and 3.3V power to the flight controller and peripherals while offering high-precision current and voltage sensing telemetry back to the autopilot.

How does the vibration isolation system improve performance?

The mechanical vibration isolation system uses damping materials and a floating mount to decouple the IMU sensors from high-frequency motor and propeller vibrations. This filtering results in cleaner accelerometer and gyroscope data, which significantly improves the state estimator's accuracy, leading to smoother flight and more precise position hold, especially on larger multirotor platforms.

Package Includes

  • 1 x Pixhawk 6X-RT Flight Controller Module
  • 1 x Pixhawk Standard Baseboard v2B
  • 1 x PM02D HV Power Module
  • 1 x Cable Set

Additional Information

Weight 0.254 kg
Dimensions 14 × 10 × 8 cm