SKU: IOWC-0192
📋 GST Invoice Available

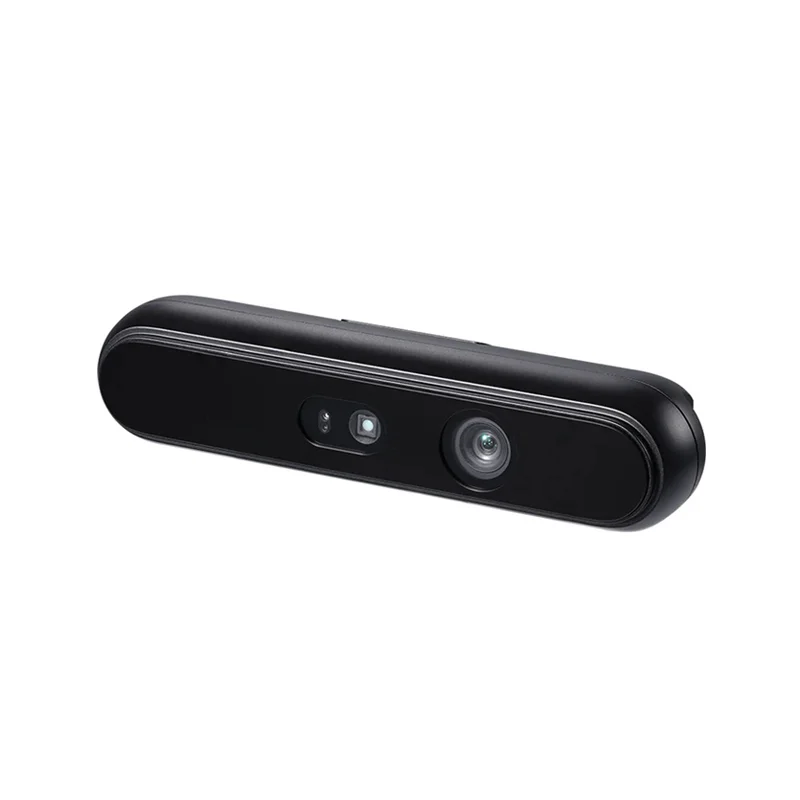
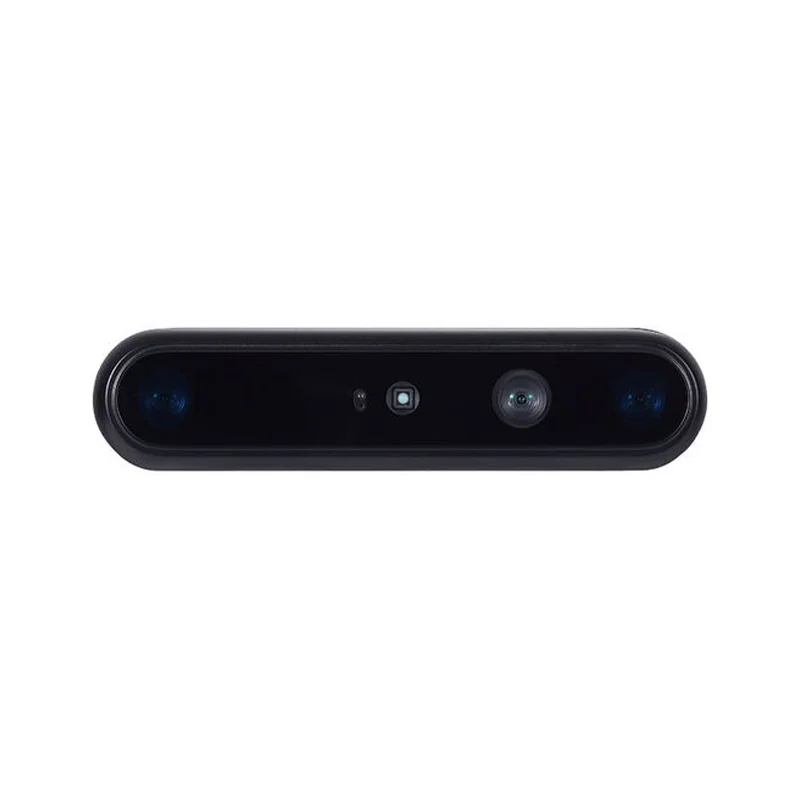
Orbbec Gemini 336L Stereo Depth Camera w/ Active IR & IMU

₹54,439.00 (Inclusive of all taxes)
Out of Stock

The Orbbec Gemini 336L is a high-precision stereo depth camera integrating both active and passive IR vision with a custom ASIC for real-time depth and RGB data. It delivers robust 3D sensing from complete darkness to bright sunlight via a single USB-C connection, ideal for robotics and computer vision applications.

Features

  • Active + Passive Stereo Vision: Combines IR projector and stereo imaging for reliable depth sensing in any lighting condition, from total darkness to direct sunlight.
  • Onboard ASIC Processing: Features Orbbec’s custom ASIC for low-latency depth computation and color alignment, reducing host CPU/GPU load.
  • High-Resolution Depth Stream: Captures depth data at 1280×800 resolution and 30 fps with a wide 90°×65° field of view for detailed environmental mapping.
  • Integrated IMU & Sync Support: Built-in inertial measurement unit and multi-camera synchronization enable stable tracking and scalable multi-sensor setups.
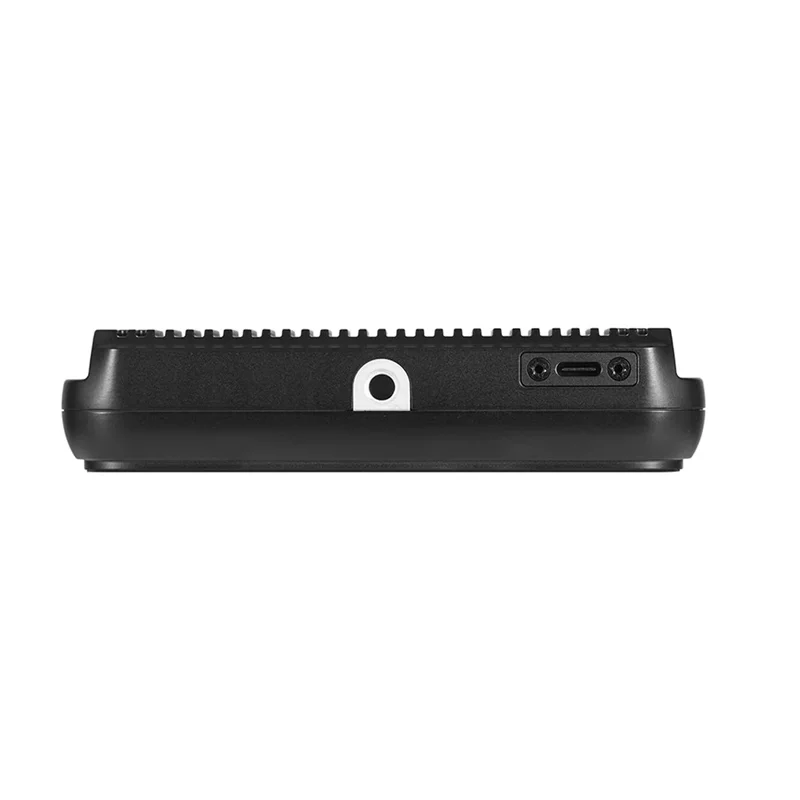
  • Single-Cable USB-C Operation: Simplified connectivity with USB-C for both data transfer and power (~3W), enabling easy integration into mobile and embedded systems.

Out of stock

Description

The Orbbec Gemini 336L Stereo Depth Camera is engineered for demanding 3D perception tasks, merging active IR projection with passive stereo imaging. This hybrid approach, powered by Orbbec’s proprietary ASIC, ensures consistent depth accuracy and robustness across challenging and variable lighting environments, eliminating the need for external processing hardware.

With a frame rate of 30 fps at 1280×800 resolution and a broad 90°×65° field of view, the camera provides high-fidelity spatial data for dynamic scene analysis. The integrated IMU corrects for motion artifacts, while multi-camera sync capabilities allow for the creation of expansive, coordinated sensor arrays. Its compact, low-power design, operating from -10°C to 50°C, makes it suitable for deployment on autonomous platforms and in industrial settings.

Key Features

  • Hybrid Active (IR) and Passive Stereo depth sensing technology for all-lighting operation.
  • Custom Orbbec ASIC handles real-time depth computation and RGB alignment onboard.
  • Delivers high-resolution depth streams (1280x800 @ 30fps) for detailed environmental mapping.
  • Wide 90°×65° field of view captures expansive scenes in a single frame.
  • Built-in IMU provides motion data for sensor fusion and stabilization algorithms.
  • Hardware sync support enables precise timing across multiple cameras in an array.
  • Programmable depth modes allow optimization for range, accuracy, or frame rate.
  • Low-power operation via USB-C, consuming less than 3 Watts.

Applications

  • Autonomous Mobile Robots (AMRs): Provides reliable obstacle detection and navigation on challenging surfaces like glossy floors under mixed lighting.
  • 3D Scanning & Digitization: Enables high-precision scanning of objects, bodies, and environments for CAD, VR, and digital twin creation.
  • Robotic Vision & Bin Picking: Offers accurate depth perception for industrial automation, object recognition, and manipulation tasks.
  • Augmented & Virtual Reality (AR/VR): Facilitates real-time environment mapping and user interaction for immersive experiences.
  • Security & Surveillance: Enhances perimeter monitoring and intrusion detection with volumetric sensing capabilities.

Technical Specifications

ModelGemini 336L
TechnologyPassive + Active Stereo IR
Wavelength850 nm
Depth Resolution & Frame Rate1280×800 @ 30 fps
Field of View (FOV)90°×65°
Range (Optimal)0.25–6 m
Range (Maximum)0.17–20 m
ProcessorOrbbec ASIC
IMU SensorYes
ConnectivityUSB-C
Power InputUSB-C (~3 W)
Operating Temperature-10°C to 50°C
Dimensions (L×W)124 mm × 29 mm
Weight135 g

Frequently Asked Questions

What software SDKs are compatible with the Orbbec Gemini 336L?

The camera is supported by Orbbec's official OpenNI SDK and the cross-platform Orbbec SDK (libobsensor), which provide drivers, APIs, and sample code for Windows, Linux, and macOS. It also integrates with popular frameworks like ROS (Robot Operating System) via the orb_slam3 or Astra packages, and can be accessed through OpenCV and PyTorch for custom computer vision and deep learning pipelines. The SDK handles depth stream acquisition, point cloud generation, and IMU data fusion.

How do I power and connect the Gemini 336L to my system?

Power and data are delivered through a single USB 3.0 Type-C cable. Connect the cable from the camera to a USB 3.0 or later port on your host PC or embedded computer (like a Raspberry Pi 4 or NVIDIA Jetson) to ensure sufficient bandwidth for the high-resolution depth stream. The camera draws less than 3 Watts. For reliable operation, avoid using long or low-quality USB cables, and ensure your host port can provide standard USB power. No external power adapter is required.

Can multiple Gemini 336L cameras be synchronized?

Yes, multiple cameras can be hardware-synchronized using the external sync input/output pins accessible via the connector on the board. This allows you to precisely align the depth frame capture times across all units, which is critical for multi-view stereo reconstruction or covering large areas. Configuration is managed through the Orbbec SDK, where you can set one camera as the master to generate a sync signal and others as slaves. This eliminates timestamp jitter and ensures coherent data fusion from all sensors in the array.

Package Includes

  • 1 x Orbbec Gemini 336L Stereo Depth Camera

Additional Information

Weight 0.135 kg
Dimensions 12.4 × 2.9 cm