SKU: IOWC-0203
📋 GST Invoice Available

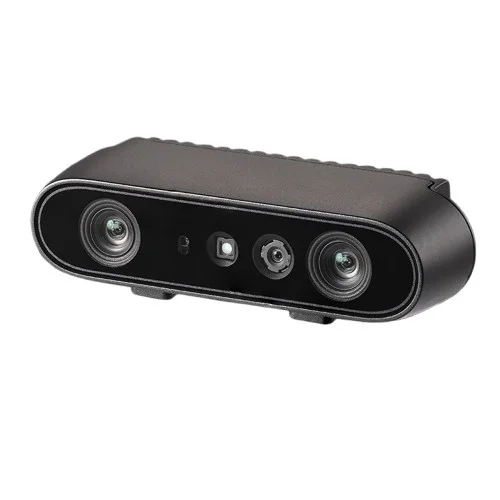
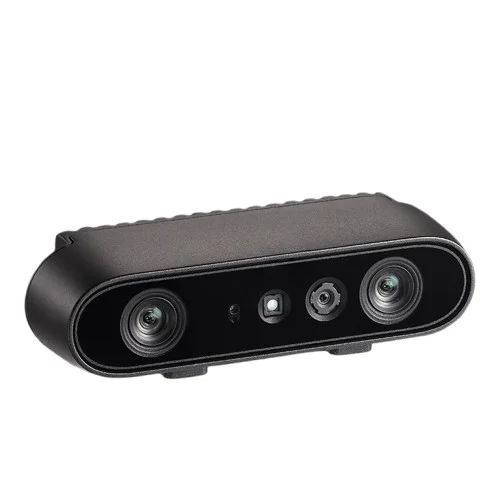
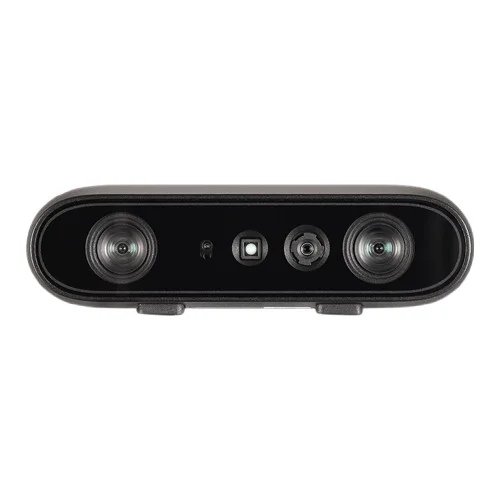
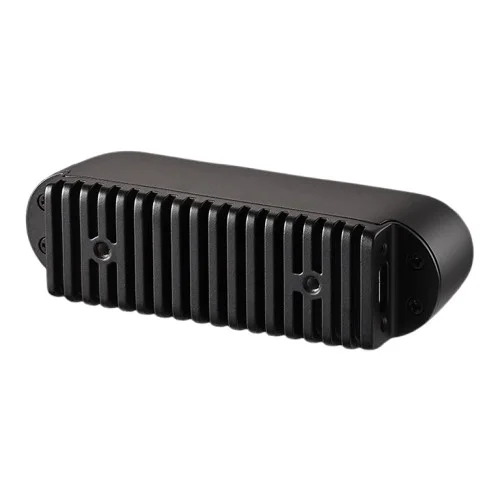
Orbbec Gemini 335 Active Stereo 3D Depth Camera w/ IMU

₹37,459.00 (Inclusive of all taxes)
Out of Stock

The Orbbec Gemini 335 is an active stereo 3D depth camera with an integrated IMU, designed for robotics and machine vision applications. It features on-board depth computation and USB-C connectivity for simplified integration with platforms like ROS, OpenCV, and the Orbbec SDK.

Features

  • Active Stereo 3D Depth Sensing with 90° x 65° wide FOV for comprehensive spatial mapping.
  • On-board processing for depth image computation and color alignment, minimizing latency and host CPU load.
  • Delivers up to 30 fps at 1280×800 depth resolution, reliable in both indoor and outdoor lighting conditions.
  • Integrated 6-DoF IMU (Gyroscope/Accelerometer) and multi-camera sync support for scalable robotic navigation systems.
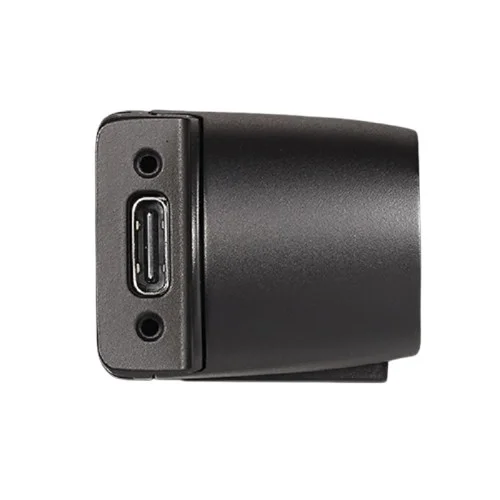
  • USB Type-C interface for combined data and power (avg. <3W), simplifying cabling and system integration.

Out of stock

Description

The Orbbec Gemini 335 Active Stereo 3D Depth Camera is engineered for demanding robotics and computer vision applications requiring real-time, accurate environmental perception. Its active stereo vision system, powered by an 850nm infrared pattern projector, generates high-fidelity depth maps with minimal latency, as all depth computation and spatial alignment are processed internally.

This camera is programmable for various depth operating modes, allowing adaptation to specific scenarios from close-range inspection to navigation. The inclusion of a 6-DoF IMU and a robust frame synchronization mechanism enables precise sensor fusion and seamless operation in multi-camera arrays, critical for autonomous mobile robots (AMRs) and collaborative robotic systems.

Key Features

  • Active Stereo Depth Technology with 850nm IR projector for robust performance in varying light, from darkness to full sunlight.
  • On-Camera Depth Processing eliminates dependency on external compute, reducing system latency and power overhead.
  • High-Frame-Rate Depth Streaming provides up to 30 fps at 1280 x 800 resolution for real-time motion tracking and mapping.
  • Programmable Depth Modes and Multi-Camera Synchronization enable flexible deployment and scalable vision systems.
  • Integrated 6-DoF IMU (50-1000Hz) supports sensor fusion for improved pose estimation and navigation accuracy.
  • USB Type-C Interface delivers both data and power (average <3W) in a single cable for clean integration.
  • Wide Field of View (90° H x 65° V) captures expansive scenes, ideal for robot navigation and spatial awareness.
  • Supported by Orbbec SDK, OpenCV, and ROS for rapid development and deployment in professional and research environments.

Applications

  • Autonomous Mobile Robots (AMR) for navigation, obstacle avoidance, and 3D mapping.
  • Delivery and Logistics Robots for parcel handling and environment perception.
  • Collaborative Robots (Cobots) for safe human-robot interaction and task guidance.
  • Bin Picking and Palletizing Systems for object recognition and robotic manipulation.
  • Augmented Reality (AR) and Mixed Reality applications requiring real-time depth sensing.

Technical Specifications

Model / NameG40155-170 (Gemini 335)
Depth TechnologyActive Stereo
IR Wavelength850 nm
Depth Resolution & Frame RateUp to 1280 x 800 @ 30 fps
Field of View (H x V)90° x 65°
IMU Sensor6-DoF (Gyroscope/Accelerometer), 50 - 1,000Hz
Power ConsumptionAverage < 3.0W (Peak 6.5W)
InterfaceUSB Type-C (Data & Power)
Dimensions (L x W)90 mm x 25 mm
Weight97 g

Frequently Asked Questions

What software frameworks are supported for the Orbbec Gemini 335 depth camera?

The camera is fully supported by the official Orbbec SDK, which provides drivers, APIs, and sample code for Windows, Linux, and Ubuntu. It is also compatible with popular open-source frameworks like OpenCV and ROS (Robot Operating System) through available wrappers and drivers, enabling rapid integration into robotics and computer vision pipelines for depth data acquisition and processing.

How is multi-camera synchronization achieved with the Gemini 335?

The Gemini 335 features a flexible hardware synchronization mechanism. Using external trigger signals or software commands via the SDK, you can precisely align the capture frames of multiple cameras. This is essential for applications like 3D reconstruction with multi-view setups or coordinating sensor arrays on a large mobile robot, ensuring timestamp-aligned data from all units.

What are the power requirements and how is the camera powered?

The camera is powered solely through its USB Type-C port, which handles both data transfer and power delivery. Average power consumption is under 3.0 Watts, with peaks up to 6.5W. You must connect it to a USB port or power adapter capable of providing at least 5V/2A to ensure stable operation, especially when the IR projector is active at full intensity.

Package Includes

  • 1 x Orbbec Gemini 335 Active Stereo 3D Depth Camera
  • 1 x USB Type-C to USB Type-A Cable (Data + Power)
  • 1 x Tripod

Additional Information

Weight 0.097 kg
Dimensions 9 × 2.5 cm