SKU: DRFC-2053
📋 GST Invoice Available

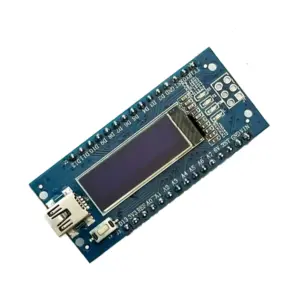
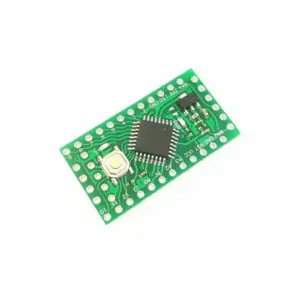
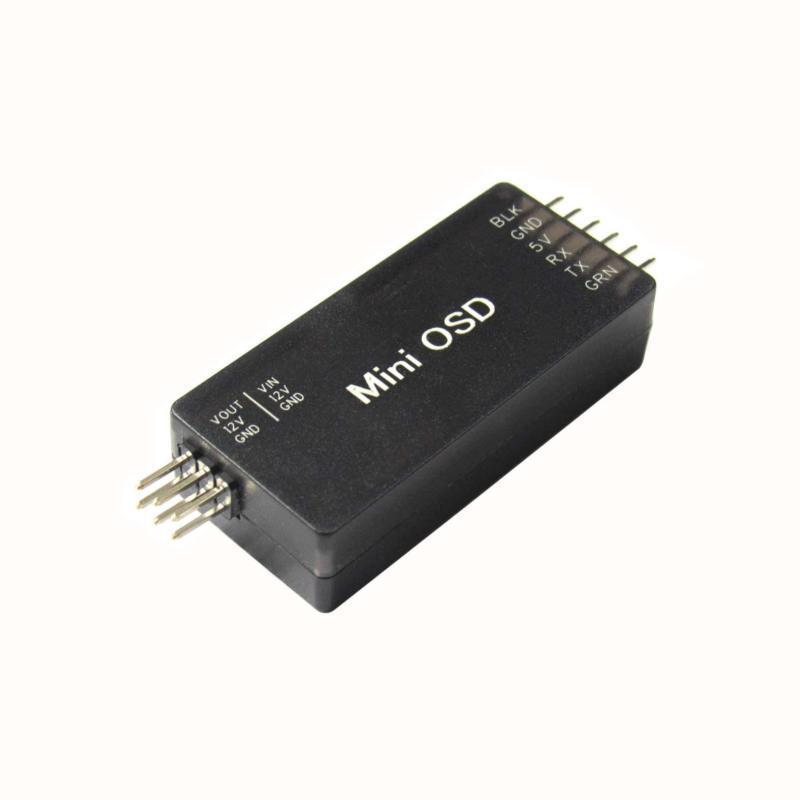
Mini OSD for Pixhawk Flight Controller Module

₹1,369.00 (Inclusive of all taxes)
Out of Stock

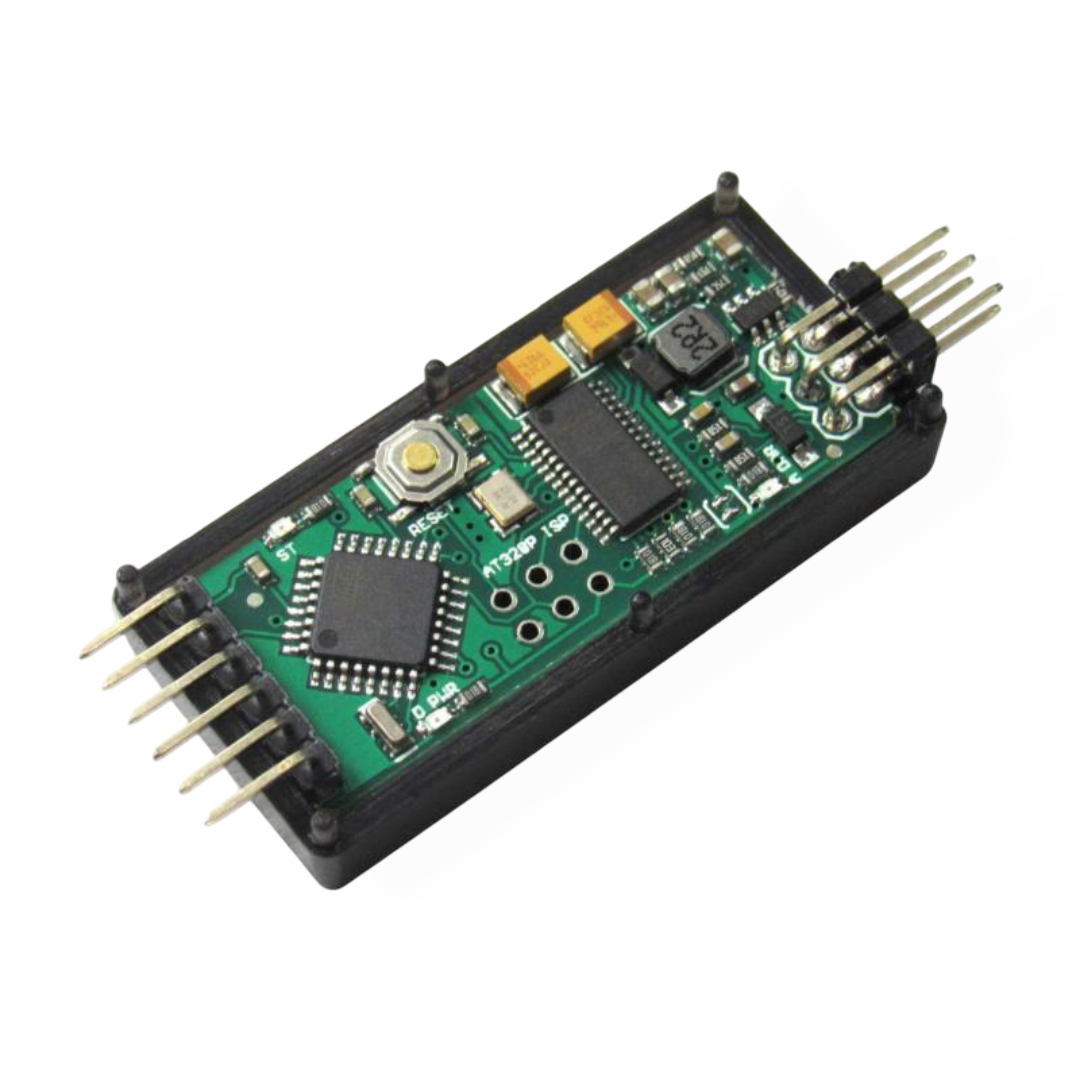
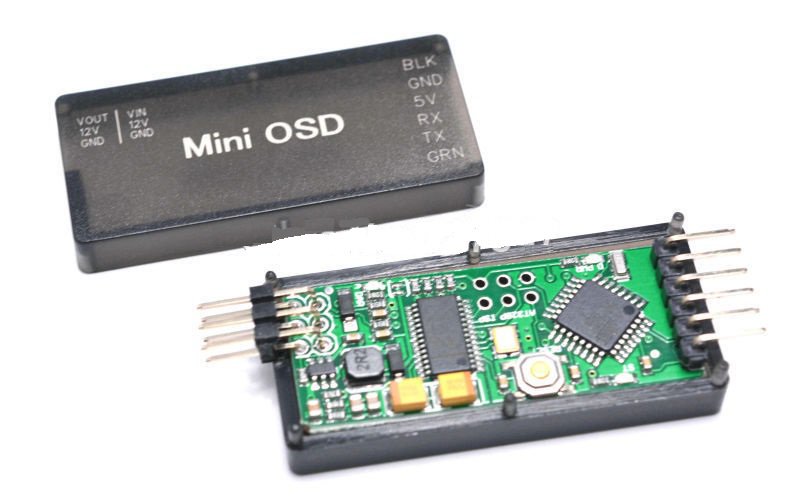
The Mini OSD for Pixhawk is a dedicated on-screen display module that reads MAVLink telemetry from APM and Pixhawk flight controllers, overlaying critical flight data onto your FPV video feed. It integrates via a standard FTDI-compatible serial connection and features independent power sections for robust operation.

Features

  • ATmega328P microcontroller pre-loaded with Arduino bootloader for easy firmware updates.
  • MAX7456 monochrome OSD chip for crisp, reliable text overlay on PAL/NTSC video signals.
  • Dual independent power sections with LED indicators and solder jumpers for flexible power configuration.
  • Direct compatibility with APM 2.5/2.6/2.8 and Pixhawk PX4 flight controllers via MAVLink telemetry stream.
  • Includes +5V 500mA regulator supporting input voltages up to +12V for versatile power supply options.

Out of stock

Description

This compact OSD module serves as a critical interface between your Pixhawk-based autopilot and your FPV video system. By parsing the MAVLink telemetry stream, it extracts essential parameters like battery voltage, GPS coordinates, flight mode, and altitude, rendering them directly onto the video feed transmitted to your goggles or ground station. This eliminates the need for a separate laptop running ground control software during flight.

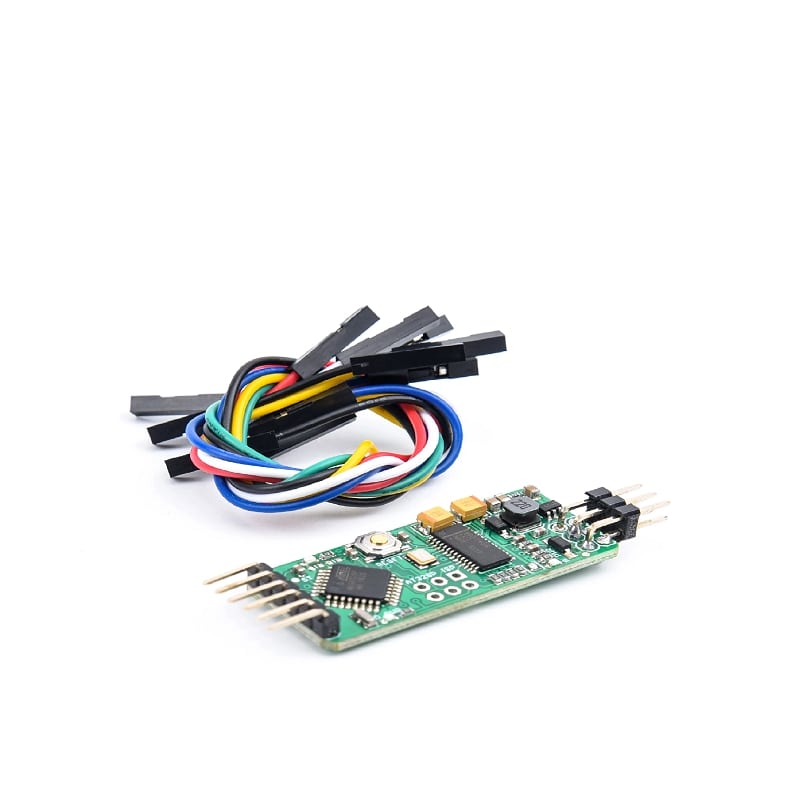
The board’s design incorporates two isolated power domains, each with its own LED indicator, allowing it to be powered independently from the flight controller or video system. Solder jumpers provide configuration options for combining these power sections or selecting PAL video standard. Exposed test points for HSYNC and LOS signals facilitate advanced troubleshooting and integration.

Key Features

  • MAVLink Telemetry Integration: Directly interfaces with APM and Pixhawk serial telemetry outputs for real-time data overlay.
  • Robust Power Design: Dual power sections with a +5V 500mA linear regulator accept inputs up to +12V, ensuring stable operation in varied electrical environments.
  • Firmware Flexibility: ATmega328P with Arduino bootloader allows for custom OSD firmware development and easy field updates via the standard 6-pin ISP header.
  • FTDI-Compatible Interface: Standard pinout enables straightforward connection using common FTDI cables for configuration and firmware flashing.
  • Video Standard Selection: Solder Jumper allows users to select between PAL and NTSC video output standards to match their camera and VTX.
  • Compact & Lightweight: Minimal footprint (58x22mm) and low weight (15g) ensure easy integration into tight multirotor and fixed-wing builds.

Applications

  • Long-range FPV fixed-wing aircraft requiring in-cockpit telemetry display via MAVLink.
  • APM or Pixhawk-based multirotor drones for real-time battery and GPS data overlay during FPV racing or aerial photography.
  • Educational and development platforms where visualizing MAVLink telemetry on a video feed is necessary for system debugging.
  • DIY rover or boat projects utilizing Pixhawk for autonomous navigation, providing operator feedback via an onboard camera feed.

Technical Specifications

Item TypeModule
Cable Length100 mm
Length58 mm
Width22 mm
Weight15 g
MicrocontrollerATmega328P with Arduino Bootloader
OSD ChipMAX7456 Monochrome
Power Regulator+5V 500mA Linear Regulator
Max Input Voltage+12V
InterfaceFTDI-Compatible Serial, 6-pin ISP Header
Compatible FCsAPM 2.5, APM 2.6, APM 2.8, Pixhawk PX4

Frequently Asked Questions

Is this OSD compatible with the latest Pixhawk 6X or Cube OrangeRX flight controllers?

No, this Mini OSD is specifically designed for the legacy MAVLink telemetry stream from APM 2.x (2.5, 2.6, 2.8) and the original Pixhawk PX4. Newer Pixhawk variants (like 6X) and Cube autopilots typically use different protocols or require a more modern, configurable OSD like the DJI OSD or integration via Betaflight for FPV quads.

How do I configure what data is displayed on the OSD?

Data display is configured by flashing custom firmware to the ATmega328P microcontroller via the 6-pin ISP header. You will need an Arduino IDE or a compatible programmer. The firmware defines which MAVLink messages are parsed and how the information is arranged and formatted on the video overlay.

Can I power the OSD from my flight controller's telemetry port, and what is the input voltage range?

Yes, one of the two independent power sections can be powered from the flight controller's serial port, typically providing 5V. The module's onboard +5V 500mA regulator can accept input voltages from 5V up to 12V, allowing you to also power it directly from your drone's main battery or a 12V video transmitter rail for isolation.

Why does the note say to disconnect USB from my APM board when using the OSD?

On APM 2.x boards, the USB port and the telemetry serial port share the same UART. Connecting both the USB cable and the OSD simultaneously creates a conflict on the serial line, which can prevent the OSD from receiving data or cause communication errors with the flight controller. Always disconnect USB before enabling the OSD link.

Package Includes

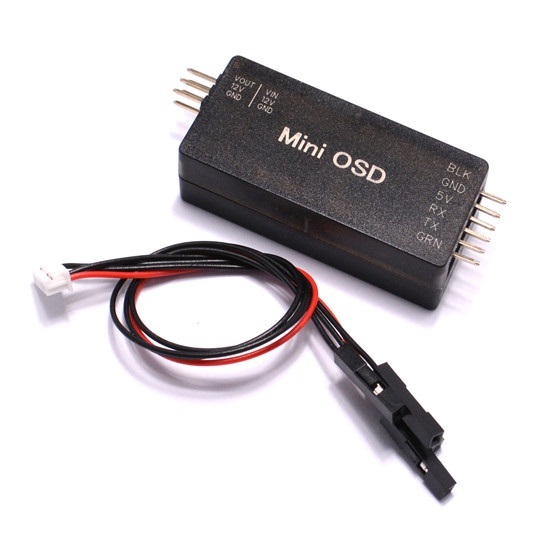
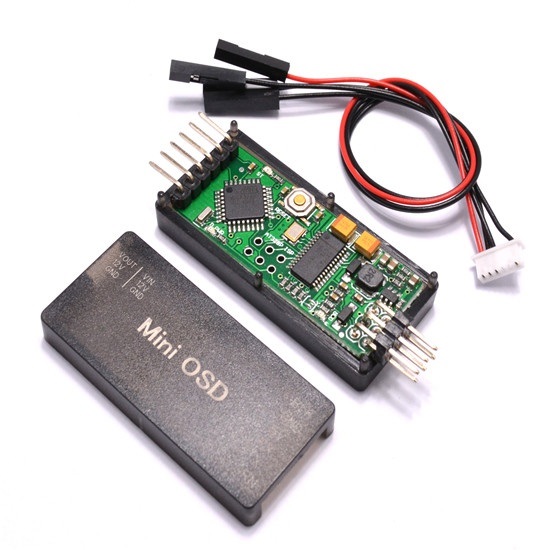
  • 1 x Mini OSD for Pixhawk Flight Controller Module
  • 1 x Set of Connecting Cables

Additional Information

Weight 0.015 kg
Dimensions 5.8 × 2.2 cm