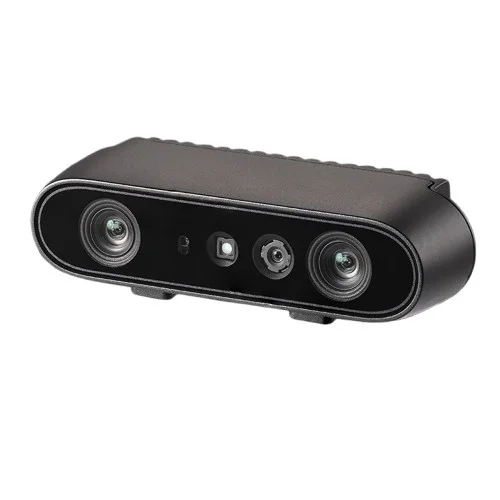
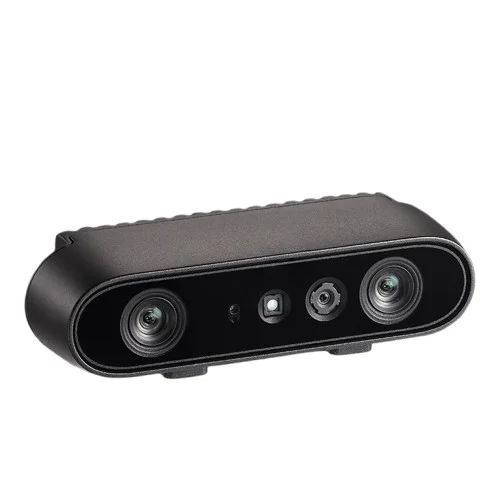
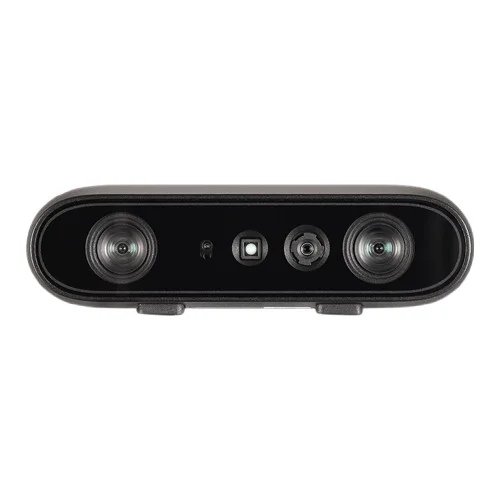
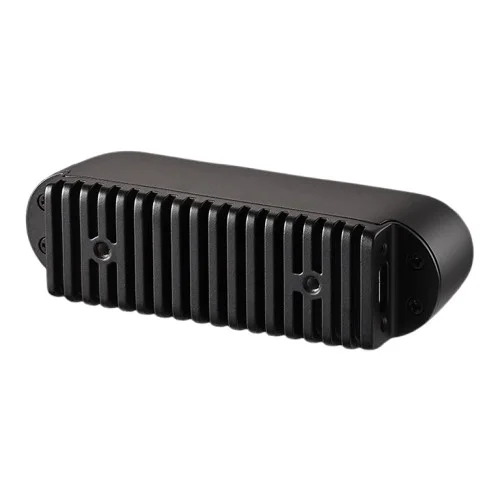
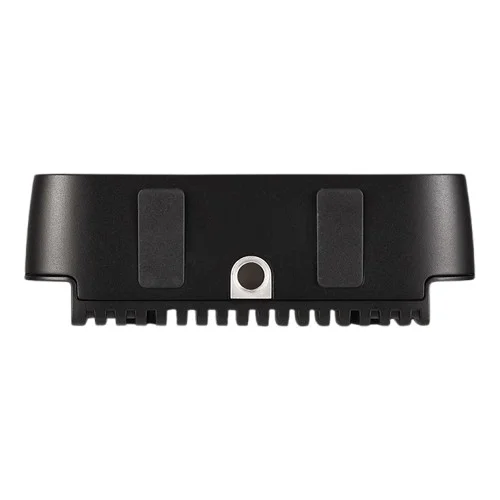
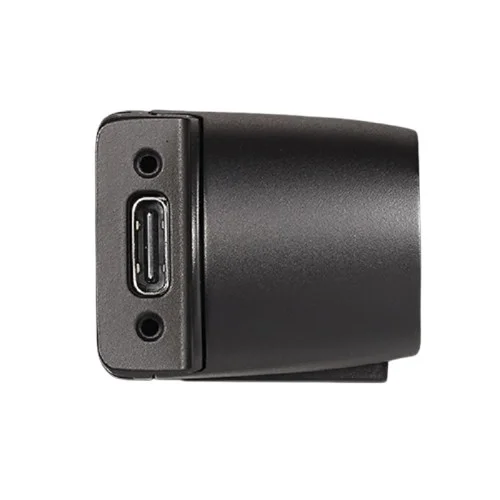
Orbbec Gemini 335 Active Stereo 3D Depth Camera w/ IMU
The Orbbec Gemini 335 is an active stereo 3D depth camera with an integrated IMU, designed for robotics and machine vision applications. It features on-board depth computation and USB-C connectivity for simplified integration with platforms like ROS, OpenCV, and the Orbbec SDK.
Features
- Active Stereo 3D Depth Sensing with 90° x 65° wide FOV for comprehensive spatial mapping.
- On-board processing for depth image computation and color alignment, minimizing latency and host CPU load.
- Delivers up to 30 fps at 1280×800 depth resolution, reliable in both indoor and outdoor lighting conditions.
- Integrated 6-DoF IMU (Gyroscope/Accelerometer) and multi-camera sync support for scalable robotic navigation systems.
- USB Type-C interface for combined data and power (avg. <3W), simplifying cabling and system integration.
Out of stock
The Orbbec Gemini 335 Active Stereo 3D Depth Camera is engineered for demanding robotics and computer vision applications requiring real-time, accurate environmental perception. Its active stereo vision system, powered by an 850nm infrared pattern projector, generates high-fidelity depth maps with minimal latency, as all depth computation and spatial alignment are processed internally.
This camera is programmable for various depth operating modes, allowing adaptation to specific scenarios from close-range inspection to navigation. The inclusion of a 6-DoF IMU and a robust frame synchronization mechanism enables precise sensor fusion and seamless operation in multi-camera arrays, critical for autonomous mobile robots (AMRs) and collaborative robotic systems.
Additional Information
| Weight | 0.097 kg |
|---|---|
| Dimensions | 9 × 2.5 cm |