SKU: SENS-1049
📋 GST Invoice Available

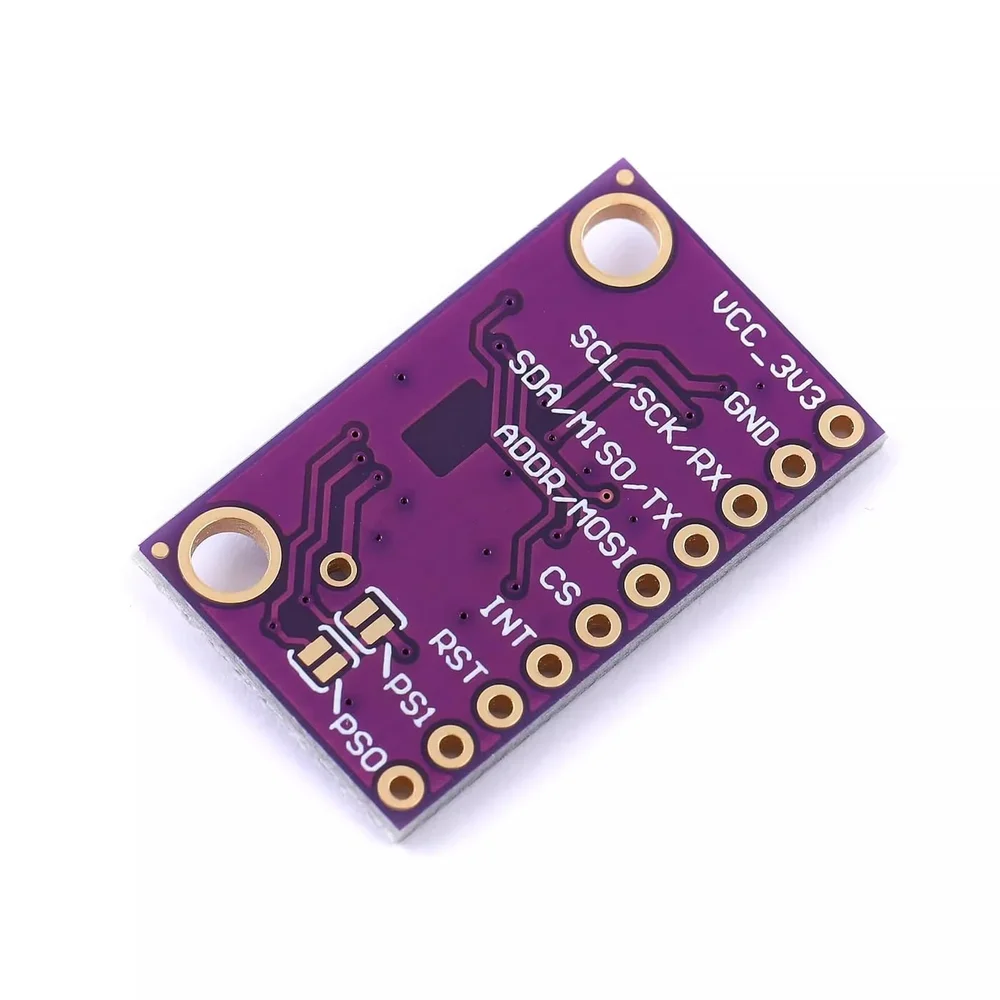
BNO085 IMU Sensor Module - I2C/SPI/UART Interface

₹2,209.00 (Inclusive of all taxes)
Out of Stock

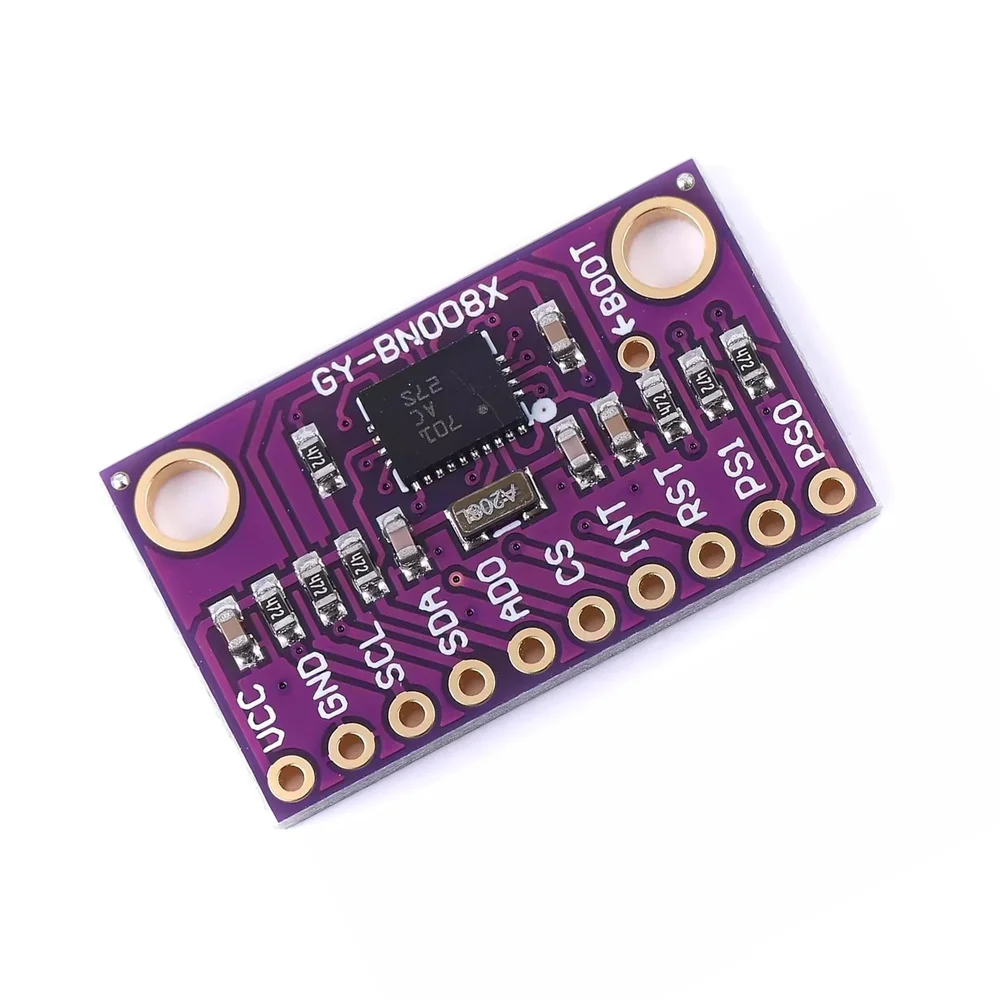
The BNO085 IMU Sensor Module is a 9-axis motion tracking sensor integrating accelerometer, gyroscope, and magnetometer, designed for precise orientation detection and motion analysis. It supports I2C, SPI, and UART communication protocols for seamless integration with Arduino, ESP32, Raspberry Pi, and other embedded platforms.

Features

  • High-precision 9-axis inertial measurement unit (IMU) with accelerometer, gyroscope, and magnetometer.
  • Multi-interface support: I2C (up to 400 kHz), SPI (up to 3 MHz), UART (up to 3 Mbps), and UART-RVC.
  • Low heading drift of 0.5° per minute and rotation Vector Technics error of 2.0° (static) to 3.5° (dynamic).
  • On-board sensor fusion provides real-time rotation Vector Technics, gravity, and linear acceleration data.
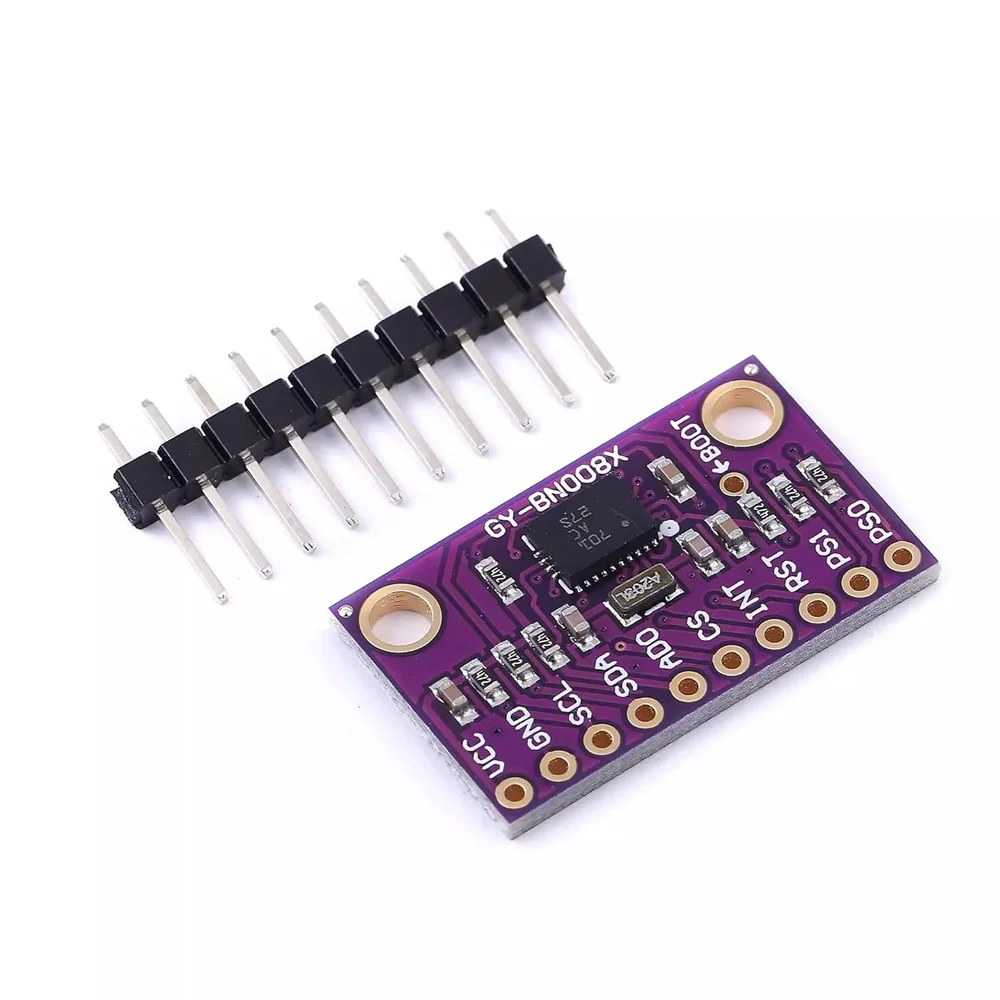
  • Compact PCB module with header pins for easy prototyping and integration into robotics and navigation systems.

Out of stock

Description

The BNO085 IMU Sensor Module is a sophisticated MEMS-based motion tracking solution that combines a 3-axis accelerometer, 3-axis gyroscope, and 3-axis magnetometer into a single, calibrated system. Its integrated sensor fusion processor (SH-2) performs real-time computation of orientation quaternions, rotation vectors, and linear acceleration, offloading complex calculations from the host microcontroller.

Designed for stability in dynamic environments, the module features advanced calibration algorithms to minimize magnetic interference and gyroscopic drift. Its multi-protocol communication suite allows flexible integration into diverse electronic architectures, from simple I2C-based Arduino projects to high-speed SPI interfaces required for drone flight controllers and robotic navigation systems.

Key Features

  • 9-axis sensor fusion for accurate orientation and motion tracking.
  • Supports I2C, SPI, UART, and UART-RVC communication protocols for maximum flexibility.
  • On-chip processing delivers calibrated rotation Vector Technics, gravity, and linear acceleration outputs.
  • Optimized for low drift and stable long-term performance in dynamic applications.
  • Compact copper PCB construction with standard 0.1" header pins for reliable prototyping.
  • Direct compatibility with popular development platforms like Arduino, ESP32, and Raspberry Pi.
  • Ideal for applications requiring precise real-time attitude and heading reference systems (AHRS).

Applications

  • Robotics navigation and autonomous vehicle orientation control.
  • Drone and UAV flight stabilization and attitude heading reference systems (AHRS).
  • Virtual reality (VR) and augmented reality (AR) motion tracking controllers.
  • Industrial equipment monitoring for tilt, vibration, and inertial measurement.
  • Gaming peripherals and human-machine interface (HMI) motion sensing.

Technical Specifications

KeyValue
Sensor Type9-axis IMU (Accelerometer, Gyroscope, Magnetometer)
Communication InterfacesI2C, SPI, UART, UART-RVC
I2C SpeedUp to 400 kHz
SPI SpeedUp to 3 MHz
UART SpeedUp to 3 Mbps
Rotation Vector Technics Error (Static)2.0°
Rotation Vector Technics Error (Dynamic)3.5°
Heading Drift0.5° per minute
Linear Acceleration Accuracy0.35 m/s²
Gyroscope Accuracy3.1°/sec
Magnetometer Accuracy1.4 µT
Measurement FunctionsRotation Vector Technics, gravity, linear acceleration
PCB MaterialCopper
Module Weight0.02 kg
CompatibilityArduino, ESP32, Raspberry Pi, STM32, etc.

Frequently Asked Questions

What communication protocols does the BNO085 module support?

The BNO085 module supports I2C (up to 400 kHz), SPI (up to 3 MHz), UART (up to 3 Mbps), and a dedicated UART-RVC mode. This multi-interface design allows flexible integration with a wide range of microcontrollers, from simple Arduino boards to high-performance ESP32 or STM32 systems requiring fast data transfer.

What is the typical rotation Vector Technics accuracy of this IMU?

The module provides a rotation Vector Technics error of 2.0° under static conditions and 3.5° under dynamic motion. It features a low heading drift of approximately 0.5° per minute, making it suitable for applications requiring stable, long-term orientation tracking without frequent recalibration.

Is the sensor data already fused and calibrated, or does it require external processing?

The BNO085 includes an integrated sensor fusion processor (SH-2) that performs all calibration and fusion algorithms on-chip. It outputs fully processed data such as rotation quaternions, linear acceleration, and gravity vectors, significantly reducing the computational load on the host microcontroller.

What is the operating voltage, and is a logic level converter needed for 3.3V systems?

The module typically operates at 3.3V logic levels. When connecting to a 5V Arduino or other 5V logic system, a logic level converter is recommended for the I2C or UART data lines to prevent damage. The power supply (VCC) range is usually 2.4V to 3.6V.

Can this module be used for drone flight stabilization?

Yes, the BNO085 is well-suited for drone and UAV applications. Its low latency, high-speed SPI interface, and accurate 9-axis sensor fusion provide the essential roll, pitch, and yaw data required for flight controllers to perform real-time stabilization and navigation tasks.

Package Includes

  • 1 x BNO085 IMU Sensor Module
  • 1 x Header Pin Strip

Additional Information

Weight 0.006 kg
Dimensions 5 × 3 × 3 cm