SKU: IOWC-0215
📋 GST Invoice Available

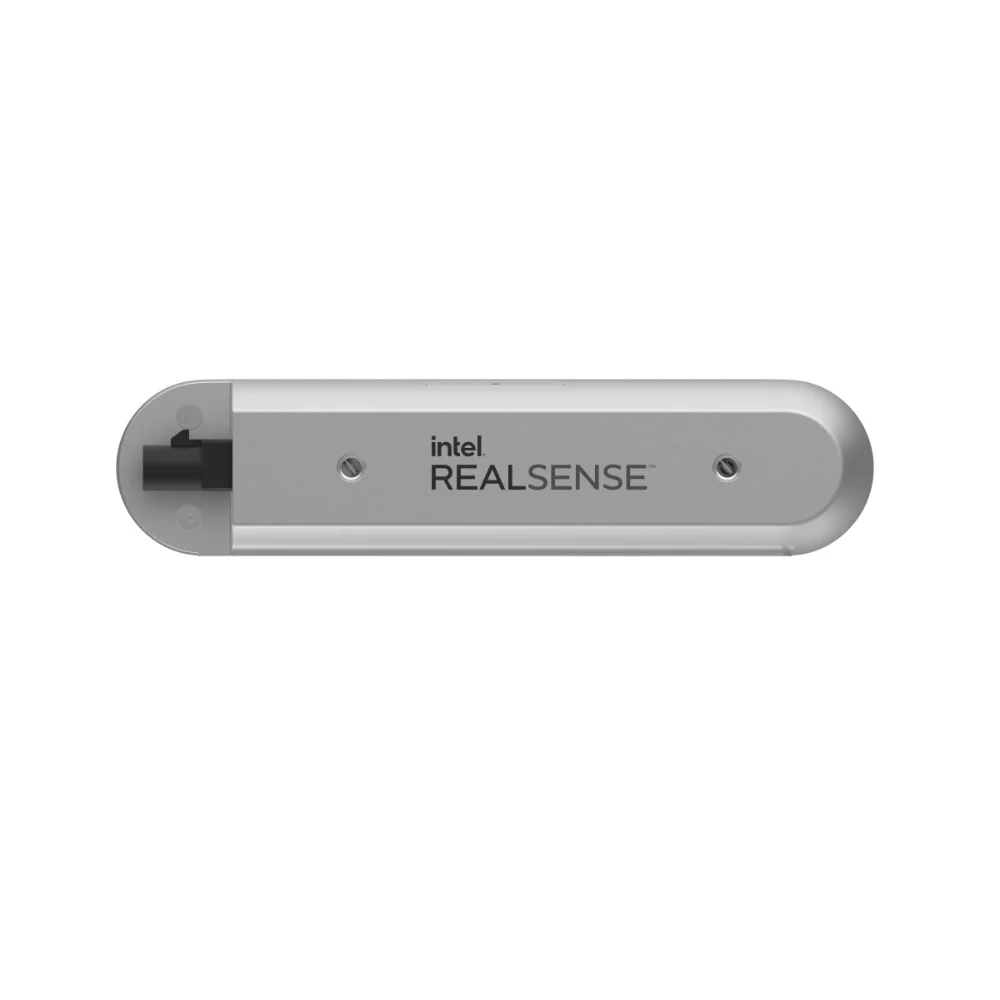
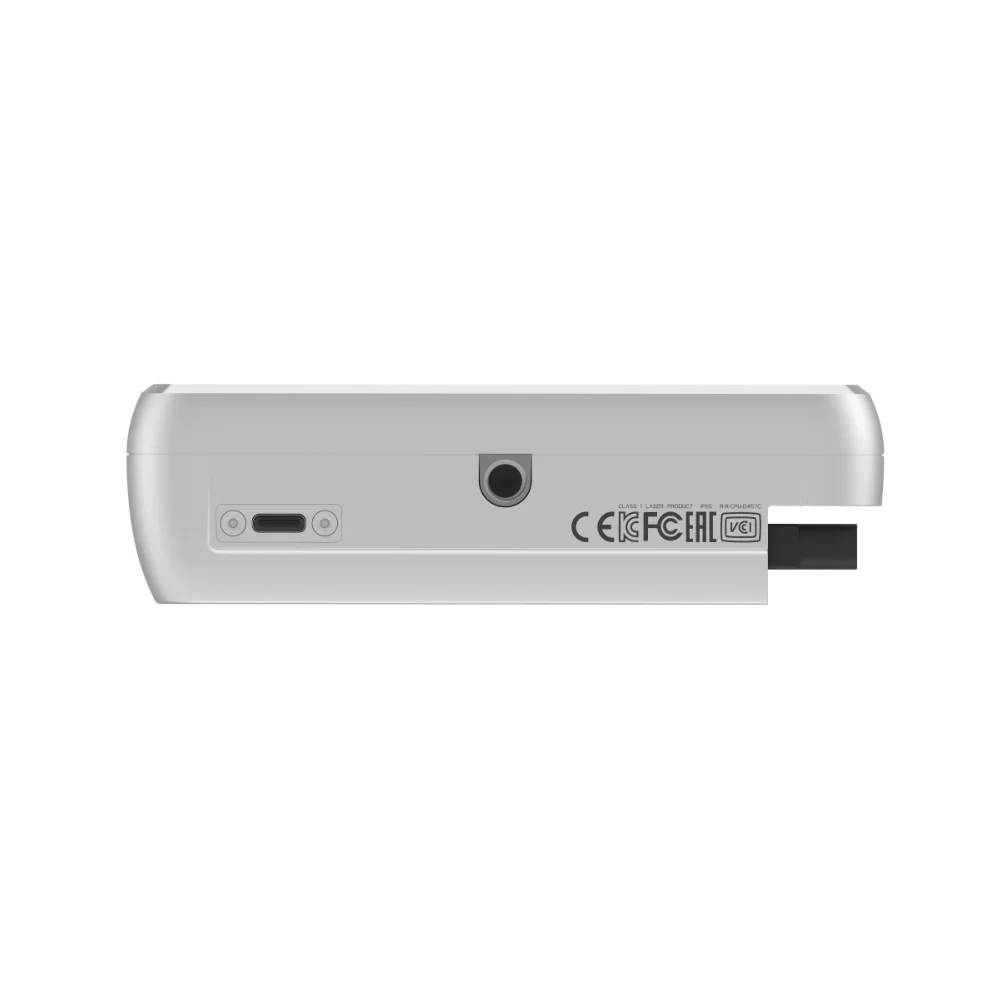
Intel Intel RealSense Depth Camera D457 w/ GMSL & FAKRA Connector

₹67,009.00 (Inclusive of all taxes)
Out of Stock

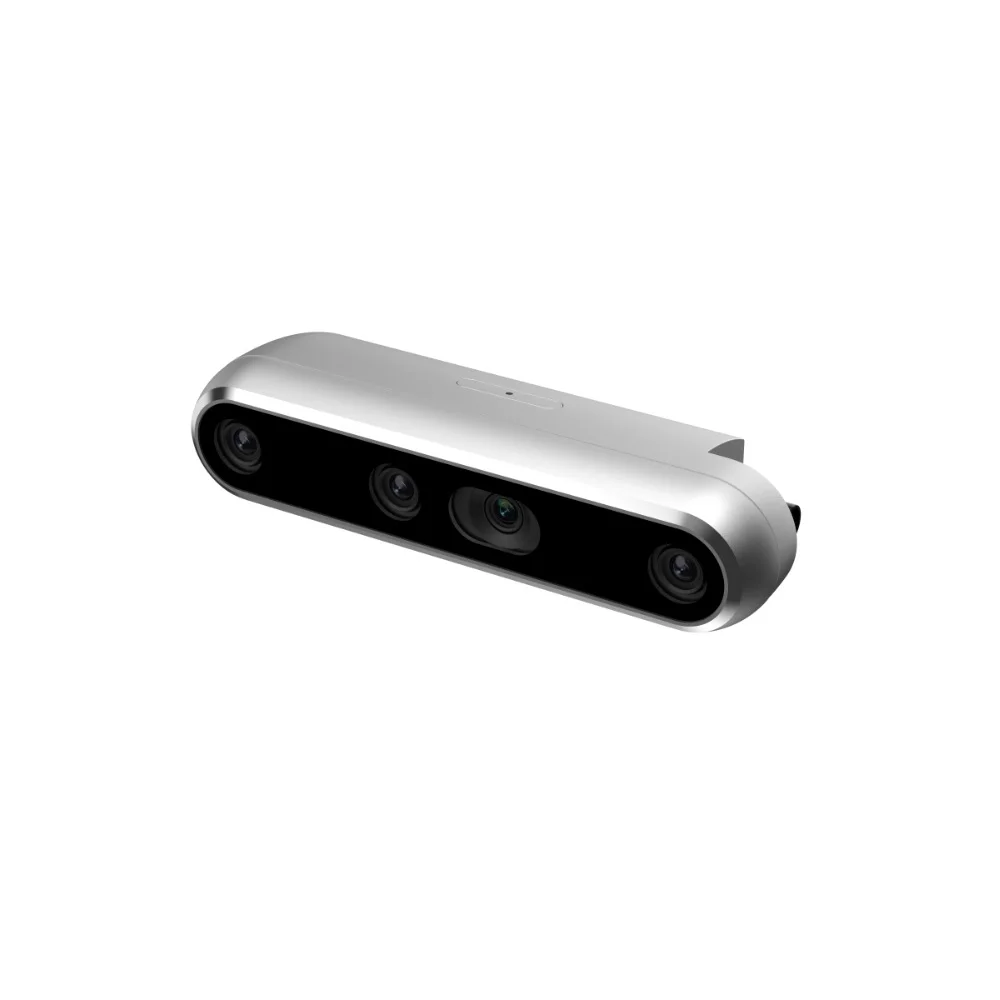
The Intel Intel RealSense D457 is a high-bandwidth stereo depth camera featuring a Gigabit Multimedia Serial Link (GMSL) interface with an automotive-grade FAKRA connector, designed for robust, low-latency 3D perception in robotics, drones, and industrial automation.

Features

  • GMSL/FAKRA interface provides high bandwidth, low latency, and extended cable runs up to 15m, ideal for automotive and robotic applications.
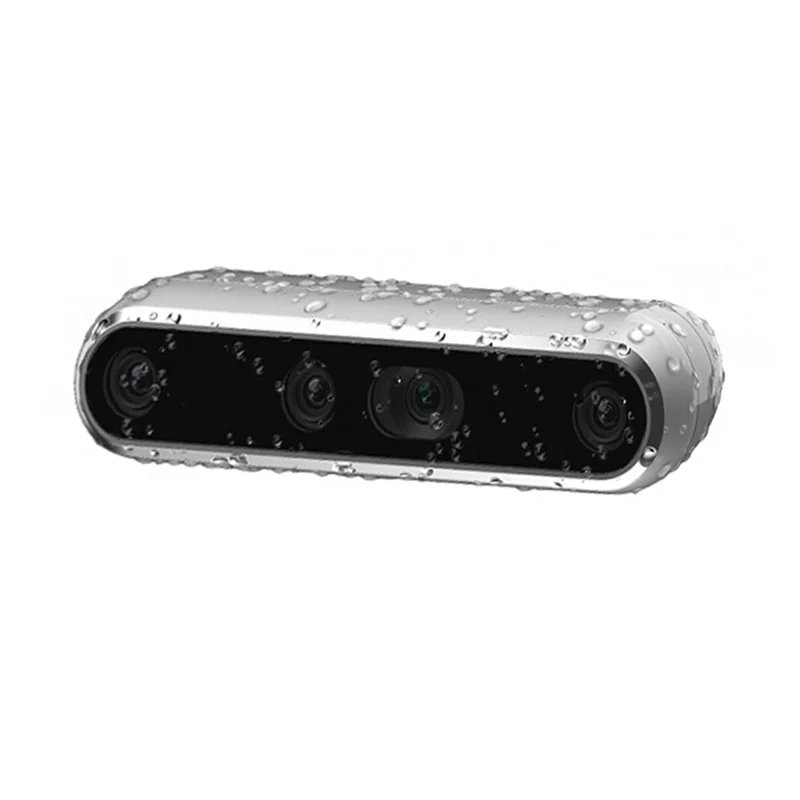
  • IP65-rated enclosure ensures protection against dust and water jets for reliable indoor/outdoor deployment.
  • Integrated IMU (Inertial Measurement Unit) refines depth data during camera motion for enhanced environmental awareness.
  • Stereoscopic depth sensing with an ideal range of 0.6m to 6m and <2% depth accuracy at 4 meters.
  • Global shutter RGB sensor and dedicated Intel RealSense Vision Processor D4 deliver synchronized depth and color streams at 30 fps.

Out of stock

Description

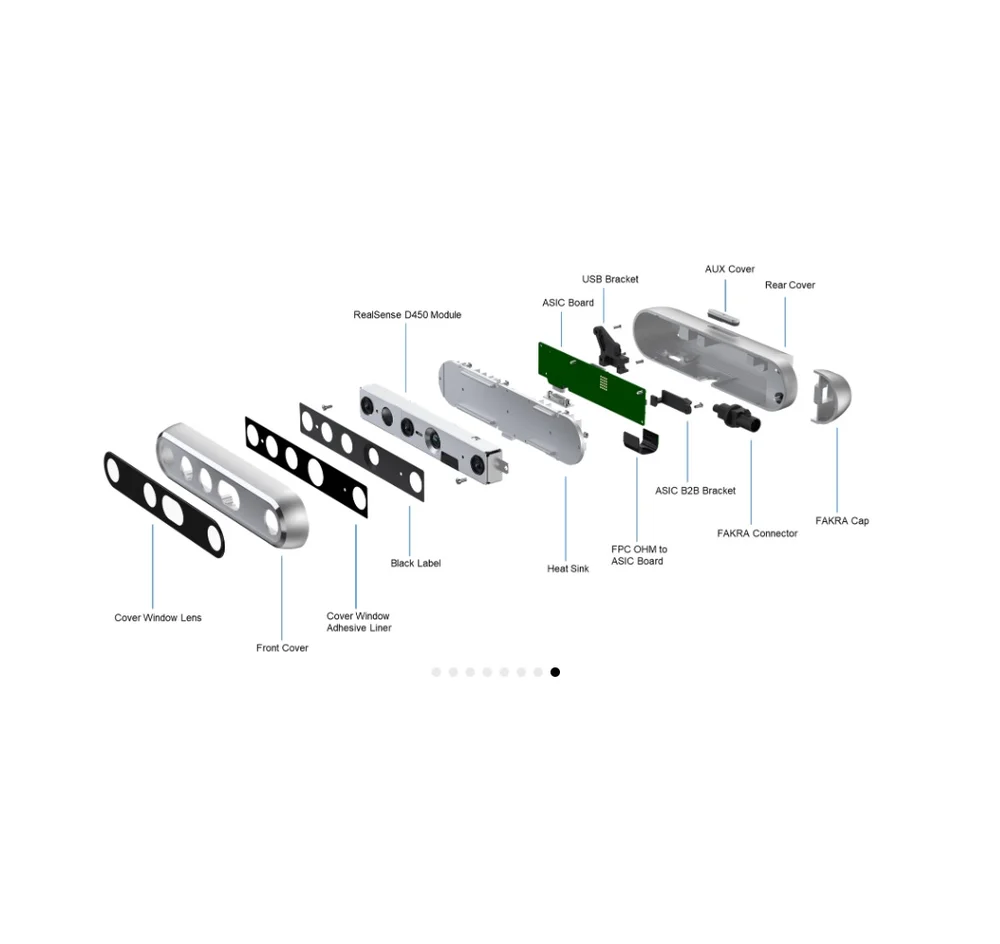
The Intel Intel RealSense Depth Camera D457 integrates advanced stereoscopic depth technology with the Gigabit Multimedia Serial Link (GMSL) protocol, a point-to-point connection standard targeting demanding automotive and industrial environments. Its FAKRA connector ensures a secure, low-ESD/EMI physical link, supporting multi-stream data transmission over a single coaxial cable for simplified system integration compared to USB or Ethernet.

Built around the Intel RealSense Vision Processor D4, the D457 delivers real-time depth processing with an accuracy of less than 2% at a 4-meter range. The camera’s IP65 enclosure safeguards its internal IMU and Maxim serializer chip from environmental factors, making it suitable for mobile platforms like autonomous drones and warehouse robots where vibration and movement are constant.

Key Features

  • GMSL/FAKRA interface enables high-bandwidth, multi-stream data over a single 15m coax cable with lower power and latency than USB.
  • IP65-rated rugged enclosure protects against dust ingress and water jets for reliable operation in harsh indoor/outdoor settings.
  • On-board IMU (Inertial Measurement Unit) corrects depth data based on camera motion, critical for dynamic robotic navigation.
  • Stereoscopic depth technology provides precise 3D perception with a wide 87° × 58° depth field of view.
  • Global shutter RGB sensor eliminates motion blur, capturing clear 1MP color images synchronized with depth frames.
  • Integrated Intel RealSense Vision Processor D4 handles complex depth calculations onboard, offloading the host system.

Applications

  • Autonomous mobile robots and drones for navigation and obstacle avoidance.
  • Warehouse automation, including bin picking, palletizing, and inventory management.
  • Industrial quality control and 3D inspection systems.
  • Automotive advanced driver-assistance systems (ADAS) and in-cabin monitoring.
  • Augmented and virtual reality (AR/VR) for spatial mapping and user interaction.

Technical Specifications

Depth Sensor TechnologyStereoscopic
Ideal Depth Range0.6 m to 6 m
Depth Accuracy<2% at 4 m
Depth FOV (H×V)87° × 58°
RGB Sensor Resolution1 MP
RGB Sensor TechnologyGlobal Shutter
RGB FOV (H×V)90° × 65°
Frame Rate30 fps
Interface / ConnectorGMSL / FAKRA
On-board ProcessorIntel RealSense Vision Processor D4
Additional SensorIntegrated IMU
Enclosure RatingIP65
Dimensions (L×W×H)124 mm × 29 mm × 36 mm
Weight0.415 kg

Frequently Asked Questions

What host-side hardware is required to interface with the Intel RealSense D457 camera?

The D457 uses a GMSL serialized output, requiring a compatible Maxim deserializer chip on the host system (like a Jetson carrier board or custom PCB) to decode the video and depth streams. You cannot connect it directly to a standard USB or Ethernet port. Ensure your host platform supports the GMSL protocol and has the appropriate FAKRA connector receptacle.

How does the integrated IMU improve the depth data output?

The onboard IMU measures the camera's linear acceleration and angular velocity. This motion data is fused with the stereoscopic depth calculations in real-time, correcting for blur or distortion caused by rapid movement or vibration. This is essential for applications like drone navigation or handheld scanning, where camera pose changes dynamically, ensuring stable and accurate 3D point clouds.

Can the D457 be used outdoors in direct sunlight or rain?

The IP65 rating protects the camera from dust ingress and water jets from any direction, making it suitable for outdoor use. However, stereoscopic depth sensing can be challenged by direct, bright sunlight (high infrared noise) or on purely reflective surfaces. For optimal performance, consider lighting conditions and surface textures, as with any optical-based depth system.

What software SDKs support the Intel RealSense D457 for application development?

Developers typically use the official Intel Intel RealSense SDK 2.0 (librealsense) for application development. The SDK provides cross-platform (Windows, Linux) APIs for accessing depth streams, color data, and IMU readings. You will need GMSL driver support from your host platform vendor (e.g., NVIDIA for Jetson) in addition to the librealsense library to enable full camera functionality.

Package Includes

  • 1 x Intel Intel RealSense Depth Camera D457

Additional Information

Weight 0.415 kg
Dimensions 12.4 × 2.9 × 3.6 cm